Welcome to the Crazyflie™ Ecosystem!
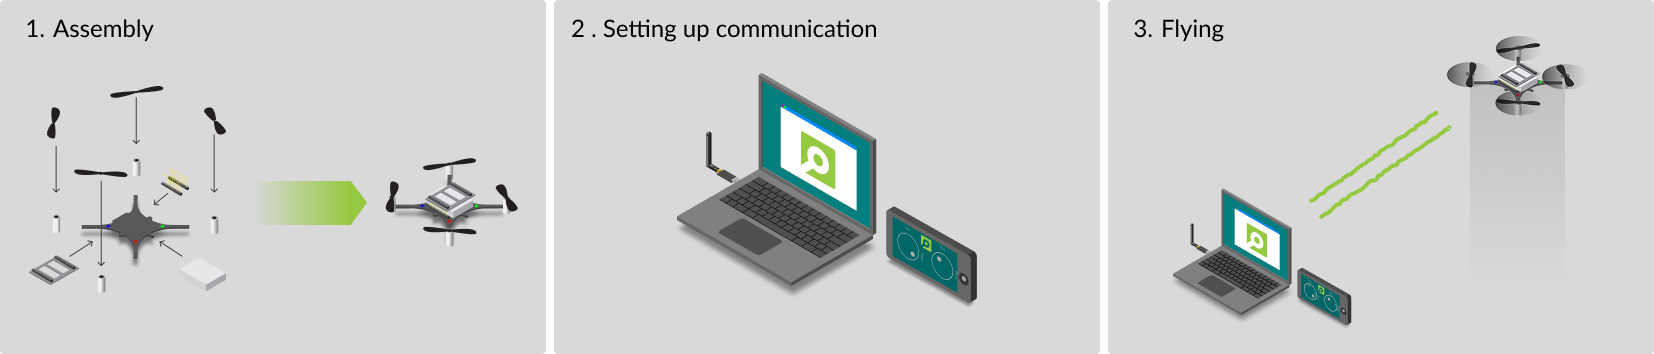
This getting started guide is split up into three parts. First we are going to assemble the Crazyflie, secondly we move on to setting up a gamepad and communication, and lastly we get up in the air and start flying. Let’s get started!
Requirements
To fly with the Crazyflie you need to have a computer with a Crazyradio 2.0 , which is the recommended way, or a mobile device. To fly manually with your computer you also need a gamepad of your choice.
If you get stuck
Don’t worry! We have many ways to figure out what might be wrong. A good place to start is to look at the Getting help page. Our documentation also provides more details than this guide. On our Github Discussions you can look at discussions from our community or start your own to get help.
1. Assembly
Make sure to follow the instructions below for assembling your Crazyflie 2.1 or 2.1+.
Unpacking the Crazyflie
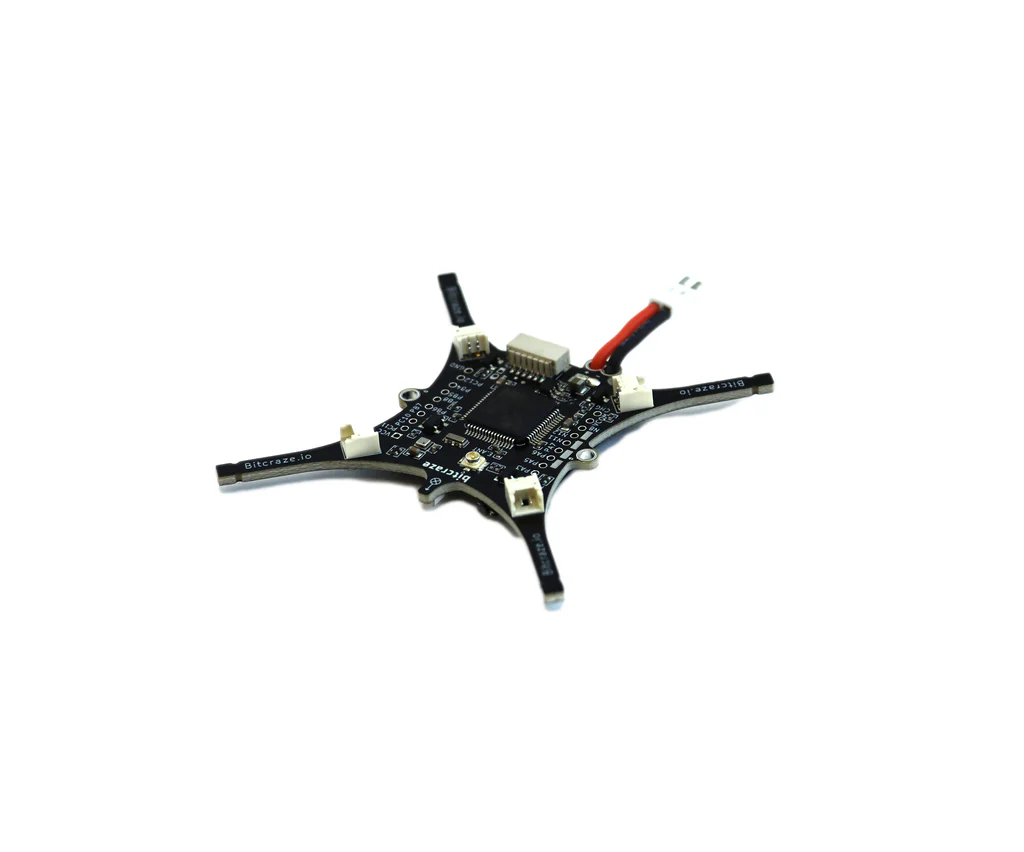
The Crazyflie box contains the following items. Make sure that you have all of them before you start assembling.
|
Crazyflie 2.0 or 2.1 control board with all components mounted |
|
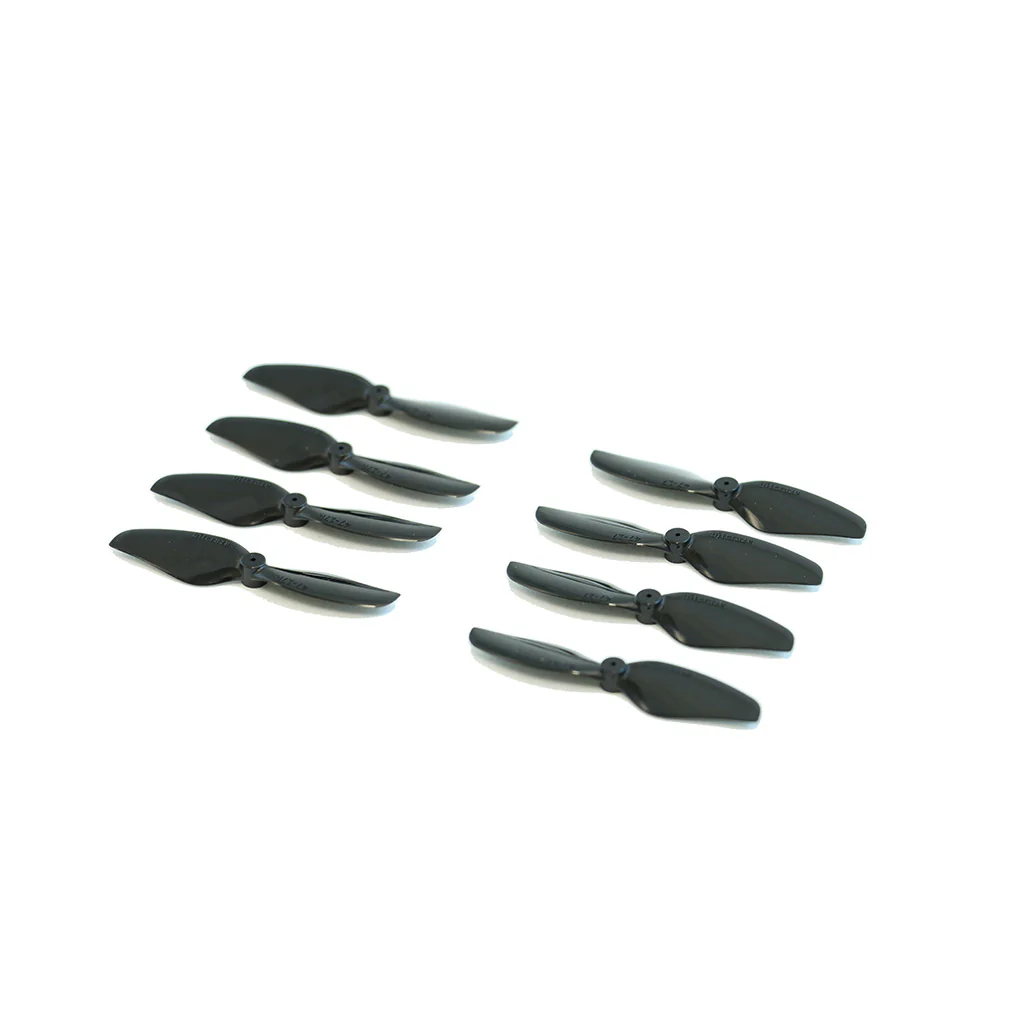
5 x Clockwise rotation (CW) propellers (3 spare, marked as "5R" on package) 5 x Counter clockwise (CCW) propellers (3 spare, marked as "5L" on package) |
|
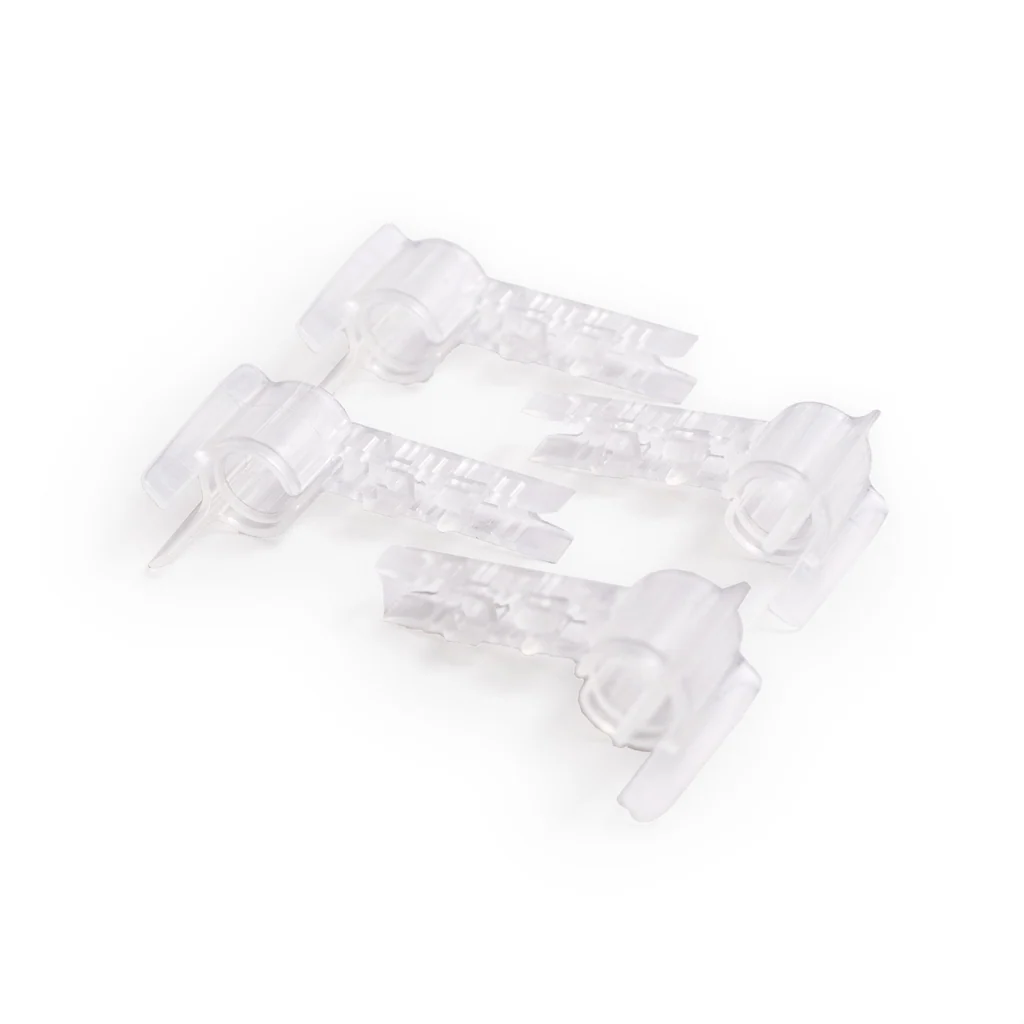
6 x Motor mounts (2 spare) |
|
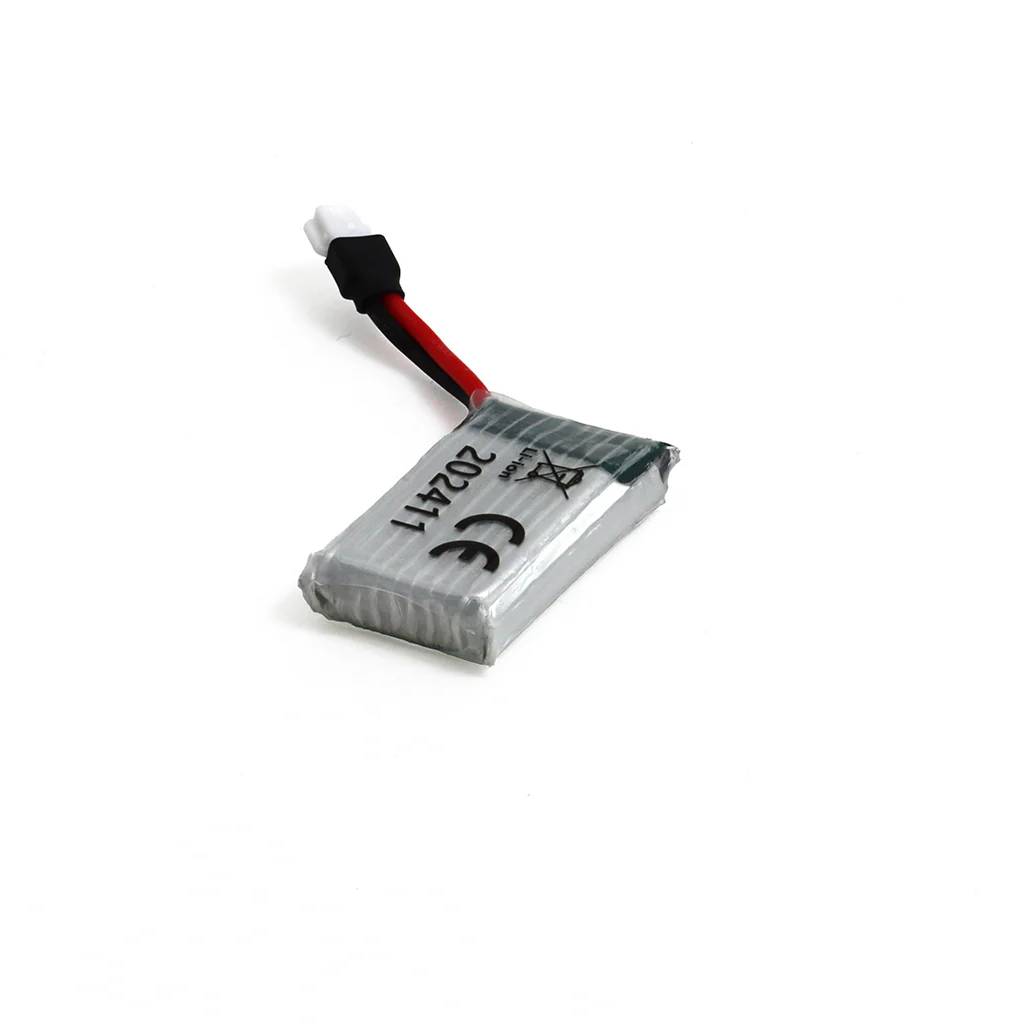
1 x 250mAh LiPo battery |
|
5 x Coreless DC motors (1 spare) |
|
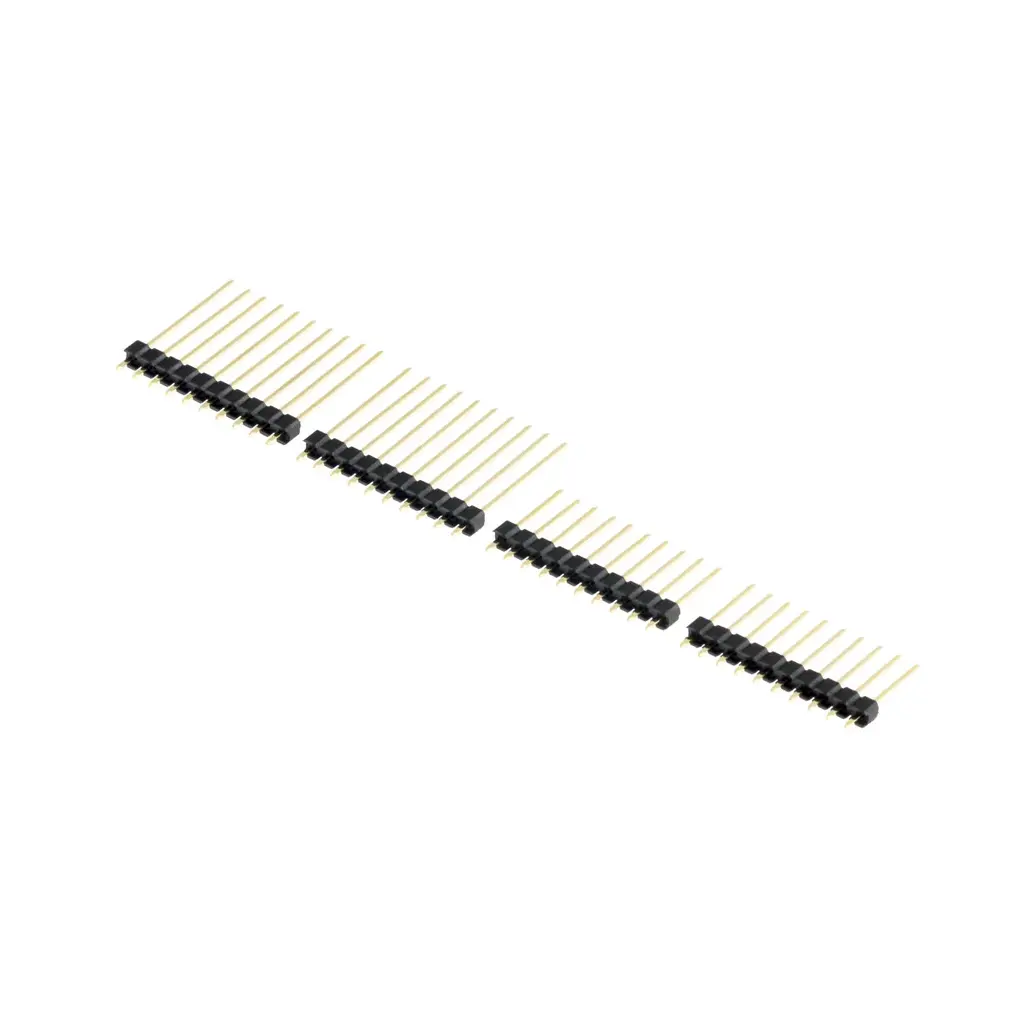
2 x Short expansion connector pins (1×10, 2mm spacing, 8 or 9 mm long) 2 x Long expansion connector pins (1×10, 2mm spacing, 14 or 15 mm long) |
|
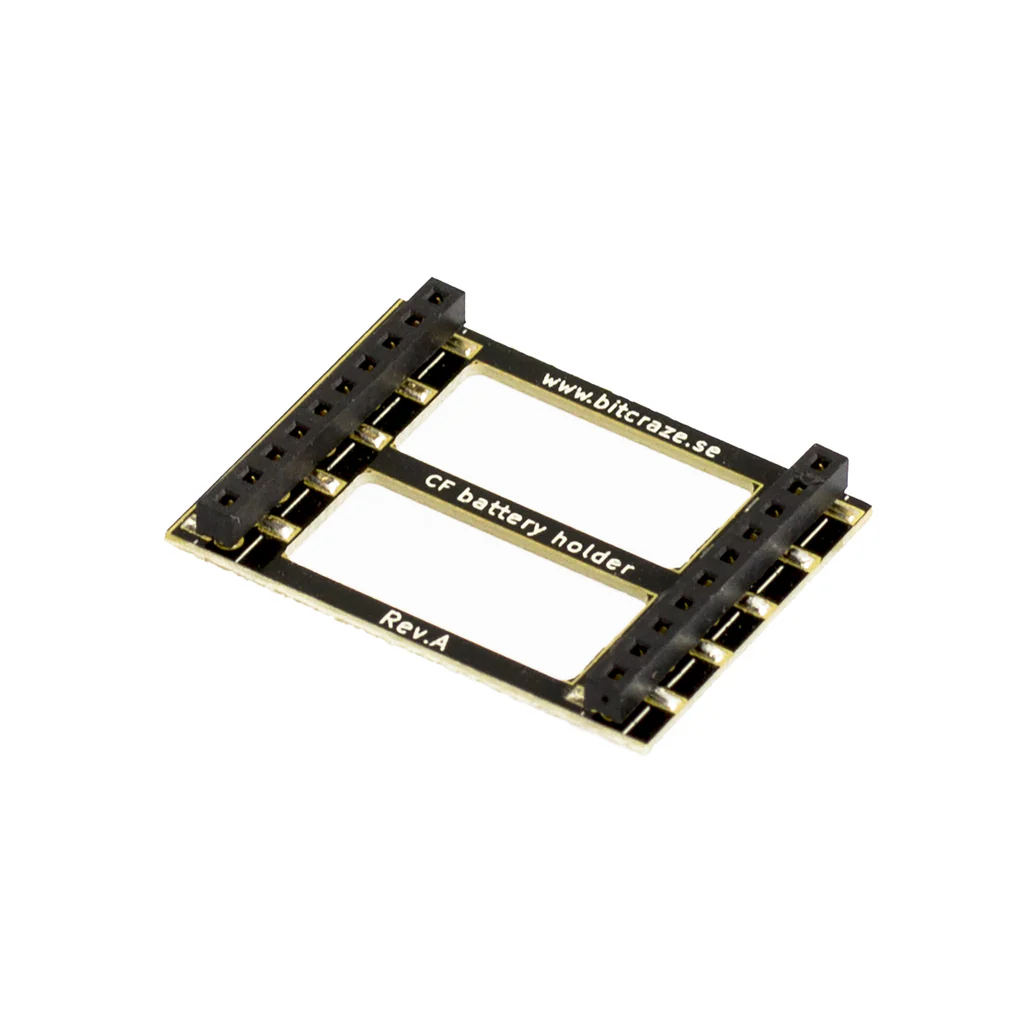
1 x Battery holder expansion board |
|
1 x Foam pad |
|
1 x USB cable |
Getting to know your Crazyflie
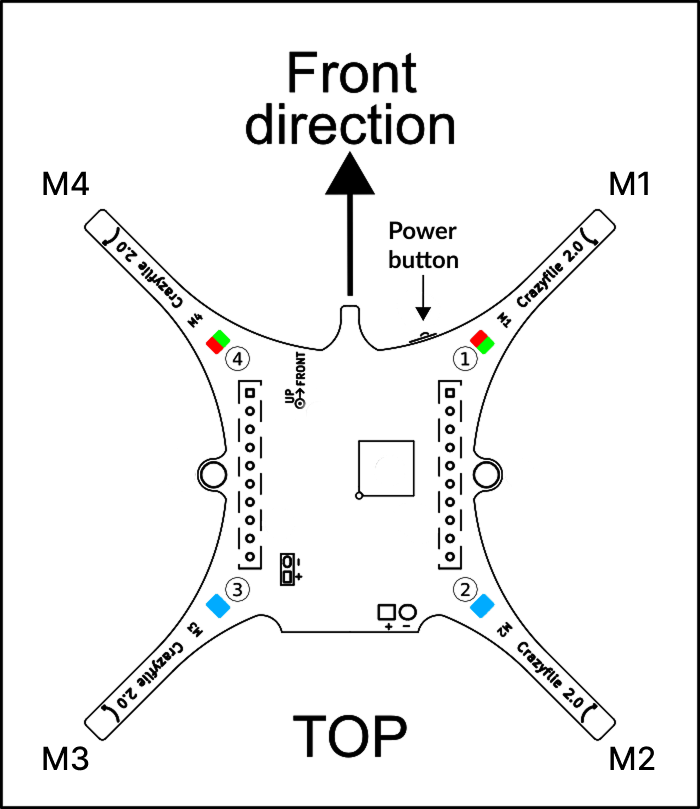
First of all, lets look at what is front and back before starting. This is a good reference point while assembling the Crazyflie, later when flying, as well as in the future when mounting expansion decks. The small “bump” (the antenna) is on the front of the Crazyflie. On the top you can also see that each arm has an LED. Here you can also see where the power button and M1, M2, M3 and M4 are.
Testing
The Crazyflie is tested extensively when produced, but to make sure nothing has happened during shipping or storage you should run the tests before starting the assembly.
Self-test
Before you start assembling anything, run the power on self-test by connecting the Crazyflie to a USB power source (either computer or charger). Note that it’s important to lay the Crazyflie on a flat surface during the test and away from strong magnetic sources. The LEDs M1 and M4 will indicate the result of the test. If the M4 LED blinks GREEN five times fast, then the test has passed.
Self-test fails
If the self-test fails, then the M1 LED blinks 5 times fast RED, then pauses and does it again. In case of failure, go to our Support Discussions to get help.
Assembling
Make sure to follow the instructions below for assembling your Crazyflie®.
Twisting the wires
Start by twisting the wires of the four motors. This will reduce electronic noise and make the wires fit better in the motor mount “hooks”.
Insert the motors into the mounts
Push the four motors into the motor mounts. You will need some force to insert them. If it is difficult doing it as in the video, try putting the motor can towards a table edge and press on the mount. However, don’t press on the motor axis while inserting them as it might damage the motor. The motor should be inserted all the way to the stop in the mount.
Attach the twisted wire
Attach the twisted wire into the two small “hooks” that are underneath the motor mount.
Mount the motors
Insert the motor mounts on the Crazyflie wings. They are press fit and might need a small amount of force. Make sure they go all the way to the stop. It’s not important which motor you put where. After it’s been inserted, connect the motor connectors to the Crazyflie.
Attach the propellers
Now it’s time to attach the propellers.
Before attaching:
There are two kinds of propellers, the clock wise (CW) and counter clock wise (CCW) propellers, each kind has their own bag in the box:
- Clock wise (CW): The packaging for the propellers are marked “5R” for right/CW. The propellers are marked “47-17R” for CW on the propeller itself.
- Counter clock wise (CCW): The packaging for the propellers are marked “5L” for left/CCW. The propellers are marked “47-17” for CCW on the propeller itself.
Attaching:
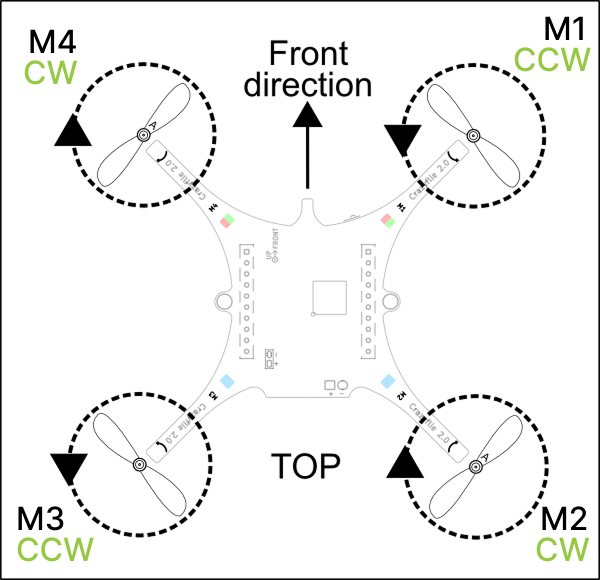
- Make sure that the correct side is facing up, the top side should be convex (the text on the propeller should be up).
- The arrow on the arm of the Crazyflie indicates what rotation direction the propeller should have.
- In the video below we are attaching the CCW propellers for the Crazyflie 2.1+.
Here’s a detailed view of where to attach CW and CCW propellers:
Attach the foam pad
The foam pad should be attached to the Crazyflie between the expansion connector pins. This will create friction, keep the battery from slipping out and also protect the electronics.
Attach expansion connector pins
There are two types of pins in the box, long and short ones. Find the long ones and insert them into the expansion connector from below.
Attach the battery
Place the battery between the pins and insert the battery holder board onto the pins. Watch out for the pins that can be a bit sharp when inserting it. Have the side of the battery holder with the text facing up. The friction should hold the battery in place so tighten it until it does.
Now connect the battery and you are finished with the assembly. The battery wires can preferably be bent and placed underneath the PCB to be out of the way.
Power on!
The assembly is finished, now it’s time to power it on! While powering on, keep the Crazyflie still on a flat surface to let it complete the start up sequence. The power button is placed on the front right of the Crazyflie, right next to the M1 LED. Note that the power button is a push button, not a sliding button.
Start up sequence
When the Crazyflie is powered on it will automatically go through a short sequence of events to get ready for flight.
- Run self tests - the Crazyflie checks that the hardware is OK. During the power-on self-test all the propellers will spin in sequence. Make sure they all spin, if they don’t then check the motor connections.
- Calibrate sensors - the Crazyflie reads its sensors to get base values. It must be absolutely still to do this, so it’s best to put it on a level surface for a second.
- Ready to fly!
Understanding the LEDs
To understand and diagnose the Crazyflie you need to understand what the LEDs mean. Here is a short explanation of each state of the LEDs:
- Power on and All is Good: The blue back LEDs (M2 and M3) are fully lit and the front right LED (M1) is blinking red twice every second (see the video in the Power on! section above.).
- Power on and All is Good, but Sensors are Not Yet Calibrated: The blue LEDs (M2 and M3) are fully lit and the front right LED (M1) is blinking red with 2 seconds interval. Put the Crazyflie on a level surface and keep it absolutely still to calibrate.
- Radio connected: The front left LED (M4) is flickering in red and/or green. The flickering of red and green means that the Crazyflie is communicating, with green indicating it is receiving data and red indicating it is sending data.
- Battery low: The front right LED (M1) is fully lit in red. It’s time to land and re-charge the battery.
- Charging: The back left blue LED (M3) is blinking while the right back blue LED (2) is lit.
- Boot loader mode: The blue LEDs (M2 and M3) at the back are blinking approximately once every second.
- Self test fail: The right front LED (M1) is repeatedly blinking five short red pulses with a longer pause between groups.
2. Setting up communication
Now that you have assembled the Crazyflie, its time to get ready to control it. To control the Crazyflie, we need to be able to communicate with it to give commands on how to fly and receive information back from the copter. You can fly the Crazyflie either from a mobile device or a computer. Choose your preferred way to control the Crazyflie below and follow the instructions to set up communication.
Choose how to control the Crazyflie:
Using your computer to control the Crazyflie will give you the most options and best control. This requires:
- A Crazyradio 2.0 .
- If you want to fly the Crazyflie manually you need a gamepad of your choice connected to your computer alongside the Crazyradio.
Installing on a computer
Setting up the radio
The first step to getting your computer ready for communication is to set up your Crazyradio 2.0 . Follow this Getting Started tutorial to set it up.
Manual Flight Control
This section describes how to get your Crazyflie ready for manual flight control.
Scripted Flight Control
This section of the tutorial introduces how to fly your Crazyflie manually, which is the best way to get started and to get to know your Crazyflie. If you want to skip this and go straight to scripted autonomous flight, follow the instructions in Next steps.
Installing the Client
There are different ways to run the Client, for example uvx, pip or through the client repository. You can see what will suit you best and follow the prerequisites and instructions to install the latest release on the Client installation instruction page.
Using the client
In this section we will look at the main features for getting started with the client. More details and features can be found in the Client user-guide.
Connect to the Crazyflie
When you have set up the client, insert the Crazyradio 2.0 in your USB-port, connect the gamepad and then start the client.
- In the Crazyflie client enter the correct Address. The default one for a new Crazyflie out of the box is 0xE7E7E7E7E7. To figure out or change the Address of your Crazyflie, you can follow the radio address configuration guide.
- Then, with your Crazyflie powered on and radio connected, click the Scan button in top left corner. The radio settings for your Crazyflie are displayed in the drop-down list.
- Choose your Crazyflie from the drop-down list.
- Click the Connect button.

Now that you have connected your Crazyflie to your client, telemetry data is continuously sent from the copter to the client. When you move the Crazyflie around you will see the flight data being updated in realtime, as well as battery status and the link quality.
Update firmware in the Crazyflie
To make sure that your Crazyflie has all the latest features you should always update the firmware to the newest version. To learn how, check out the client user-guide here.
Configure your gamepad
You can use any gamepad connected to your computer by cable or Bluetooth. The gamepad has to be connected before you start the client to be recognized by the client. After you have connected your gamepad, open the input device settings in the client. Check if the correct device mapping is chosen, otherwise pick your device type.
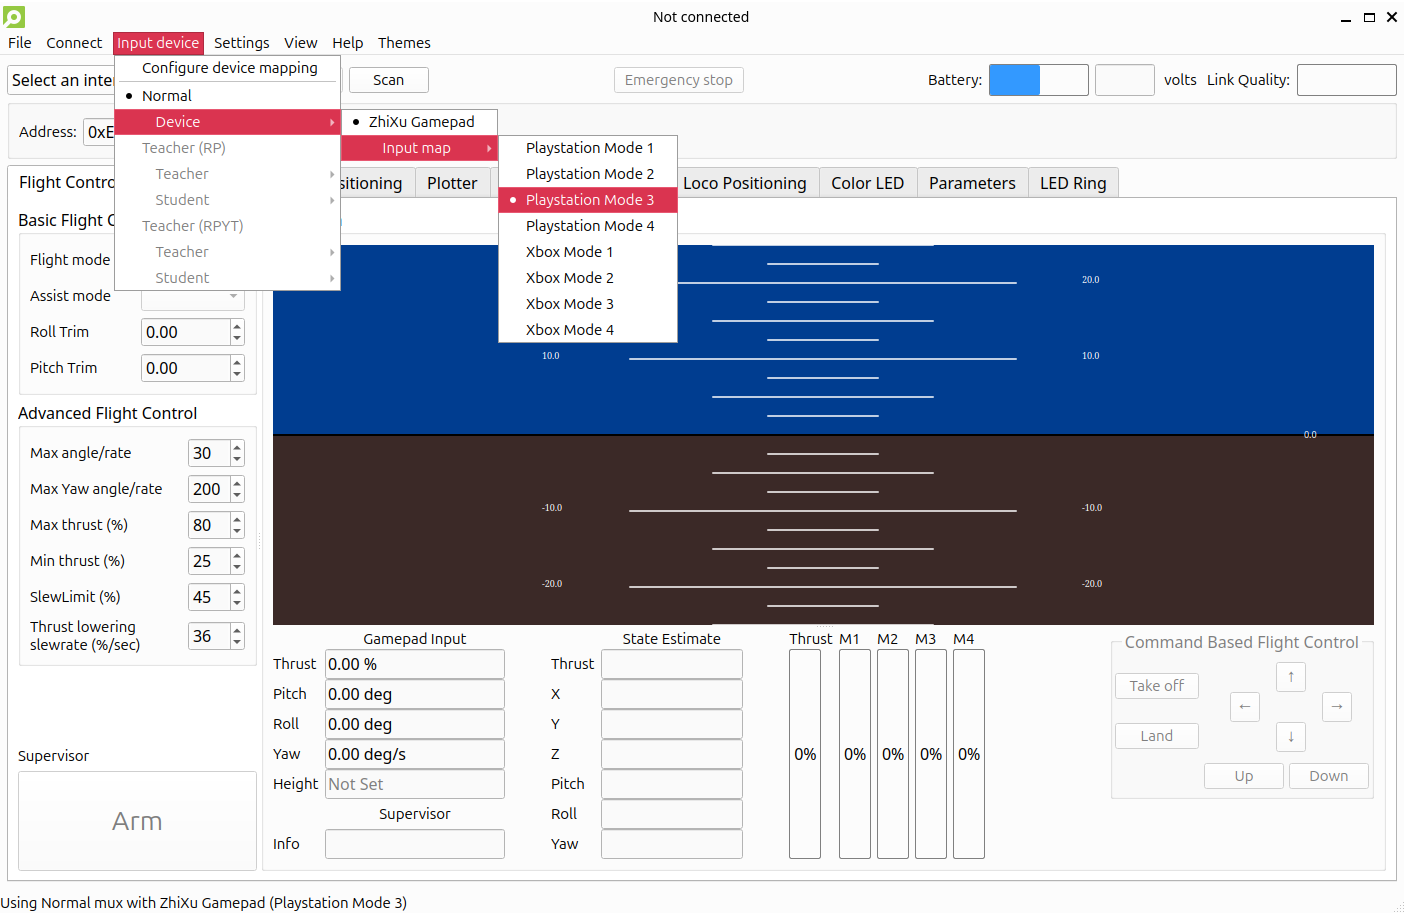
For more detailed information on input devices, see the Client user-guide. In this guide it is also shown how to configure your own device mapping to perfectly suit your gamepad.
Using a mobile device is the fastest way to get into the air, but it is designed mostly for testing purposes. If you want to get the most out of your Crazyflie, flying using a PC and Crazyradio is what we recommend.
It is easy to install the app and connect to the Crazyflie and get it flying. However, it might demand some extra piloting skills. All you need is an Android or iOS device that supports Bluetooth Low Energy (BLE).
Install the app
The Crazyflie client is available for Android and iOS.

Connect to the Crazyflie
Start the app and click the connect button. The buttons have different appearances in the Android and iOS apps, you can see them below.
Note: If you are using Android and your Crazyflie is behaving strange (like dropping from the air or is reacting slowly), turn on the “Bluetooth latency workaround” setting.

3. Flying
Now it’s time to do some flying, but first there are some basics you need to know about.
Orientation
First of all, the easiest way to fly is when the copter is pointing away from you. The blue LEDs are on the back, so keep them pointing in your direction when starting to fly.
Maneuvering a quadcopter
When flying a quadcopter there are four main dimensions of controls; roll, pitch, yaw and thrust.

- Roll - is the rotation around a horizontal axis going through the quadcopter from back to front. This rolls the Crazyflie and moves it left or right.
- Pitch - is the rotation around a horizontal axis going through the quadcopter from left to right. This tilts the Crazyflie and moves it forwards or backwards.
- Yaw - is the rotation around a vertical axis. This rotates the quadcopter left or right. Yaw is used when changing flying direction by pointing the front of the Crazyflie in different directions.
- Thrust - adjusts the altitude, or height, of the Crazyflie.
Lear more about the coordinate system of a Crazyflie here.
Gamepad / The mobile app controls
The controls on the gamepad or mobile app have multiple different input mappings to select from. A common mapping to use in a lot of flying robotics applications is mapping 3, and it is mapped the following way:

To change between mappings and gamepad types as well as creating your own custom mapping check out the documentation for input devices or the settings menu in the mobile app.
Normal flight
When thrusting without touching any other controls, this is what it might look like. The Crazyflie usually drifts in some direction if not compensated for, this is completely normal.
The Ground effect
When the copter is flying close to the ground (less than a few decimeters above the ground) it is effected by what is called the Ground effect. The feeling is that the air is slippery, almost as if it is gliding on ice. To avoid this, particularly when learning to fly, use a lot of thrust just when taking off and then ease off for level flight.
If the Crazyflie is unbalanced
Firstly, if your Crazyflies propellers spin but it does not properly take off, the most common reason is that the propellers are not placed correctly. Look at the image under Attach the propellers and make sure to place the correct propeller or the correct arm.
If your Crazyflie drifts a lot when taking off, there are a few things you should check.
- Make sure the battery is centered. If it has slipped too far to either side, the Crazyflie might have a hard time compensating for it.
- Check that the propellers are spinning freely. Blow lightly on them, one by one, and verify that they turn. A common problem is that hair or other debris is jammed between the propeller and motor. If this is the problem. just pull the propeller off from the motor, remove the hair and reinstall the propeller.
- Check that the propellers are balanced, Balancing propellers
Charging the battery
To charge the battery of the Crazyflie, plug in a micro USB cable with the battery attached. Make sure the Crazyflie is powered on. While the battery is charging, the back left blue LED will blink. When the LED is fully lit the battery is charged.
Go fly!
Have fun!
Next steps
Now that you are in the air you can explore more opportunities with our Expansion Decks, and if you already have a deck you want to attach you can check out the Getting started with expansion decks tutorial.
Scripted Flight Control
Another step is trying autonomous flight with Python scripting and the Crazyflie Python library. When flying using a script you need a Crazyradio 2.0 for communication. As a first step, you need to install and familiarize yourself with our library cflib. This software enables you to fly one or more quadcopters in predetermined way using Python to control the quadcopter. Get started with Python scripting and the Crazyflie Python library though our Step-by-step user guides. To get some inspiration on what can be done, please check out the examples and the demos repository.