Category: Research

What does it take to bring a new coordination stack to the Crazyflie? In this guest post, Jim Steele, founder of Tapestry OS, shares his experience building a Zephyr-based firmware port for the Crazyflie 2.1 Brushless and using it to explore decentralized coordination with three drones. We’re happy to welcome Jim to the blog to share the work and what he learned along the way.

The Crazyflie platform has an excellent answer to the question of how to fly a drone autonomously. The firmware is well-documented and actively maintained with hardware abstraction, sensor drivers, and state estimators providing solid infrastructure that a research team can build on confidently.

The question I kept running into is one layer above that: once you have drones that can fly reliably, how do you coordinate what a collective of them does together? Not at the trajectory level (Crazyswarm2 handles that well) but at the level of distributed state: what does each drone know about where the others are, how fresh is that information, and how does the collective continue functioning correctly when a drone fails or communication is interrupted?
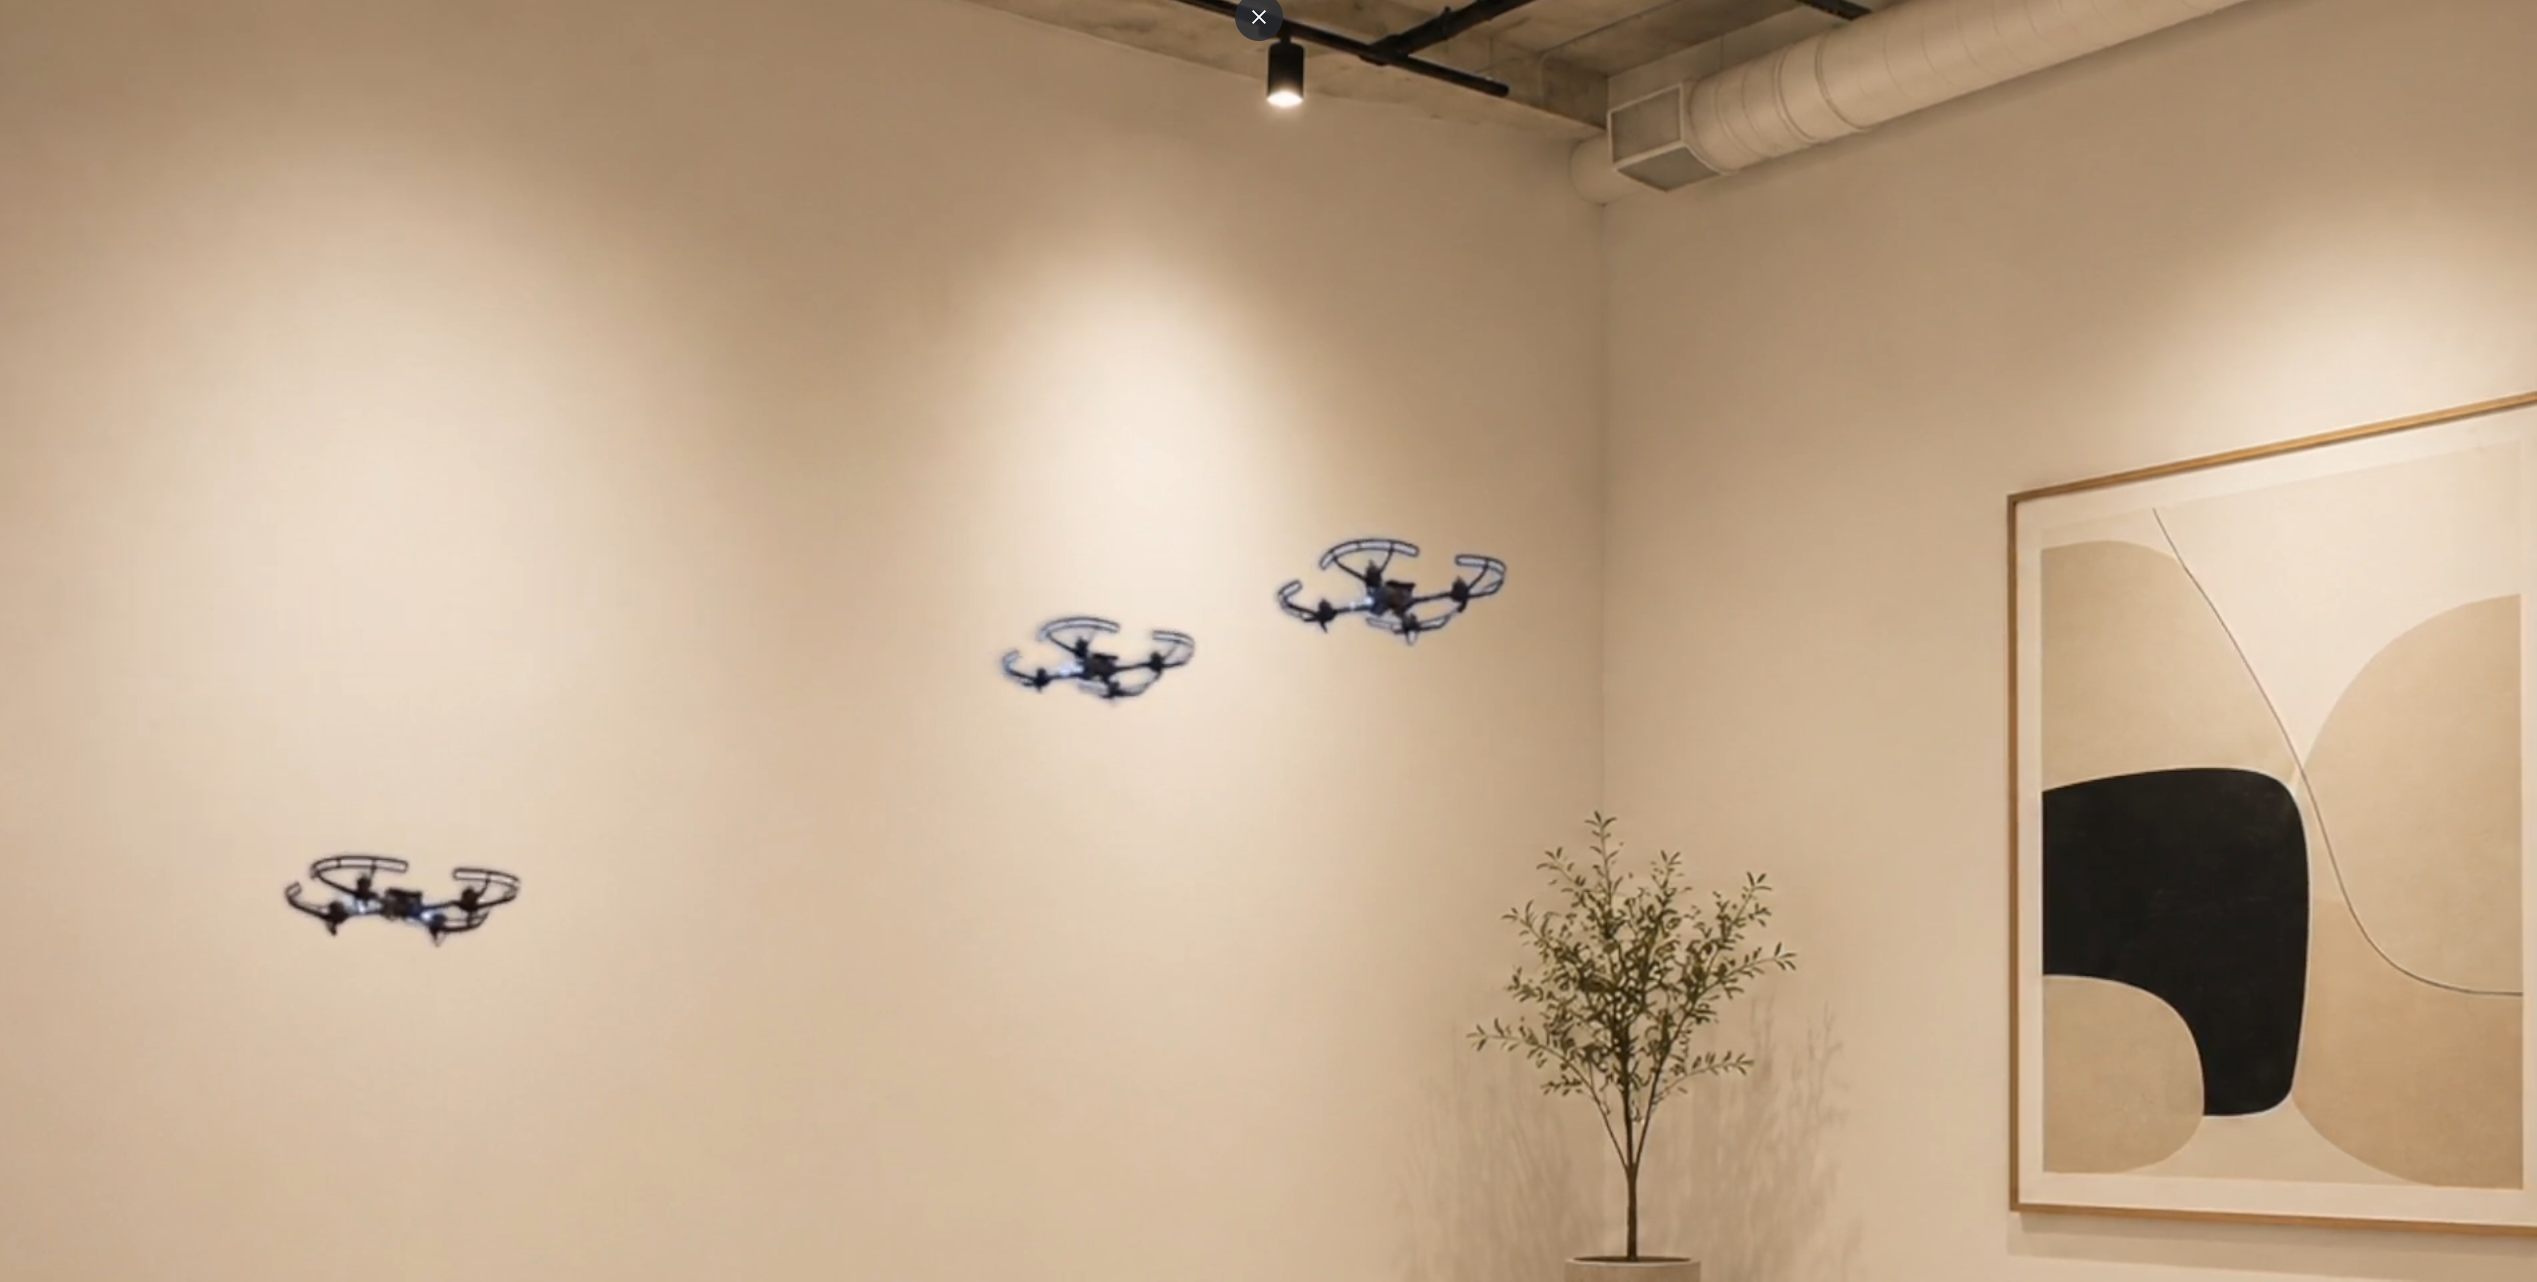
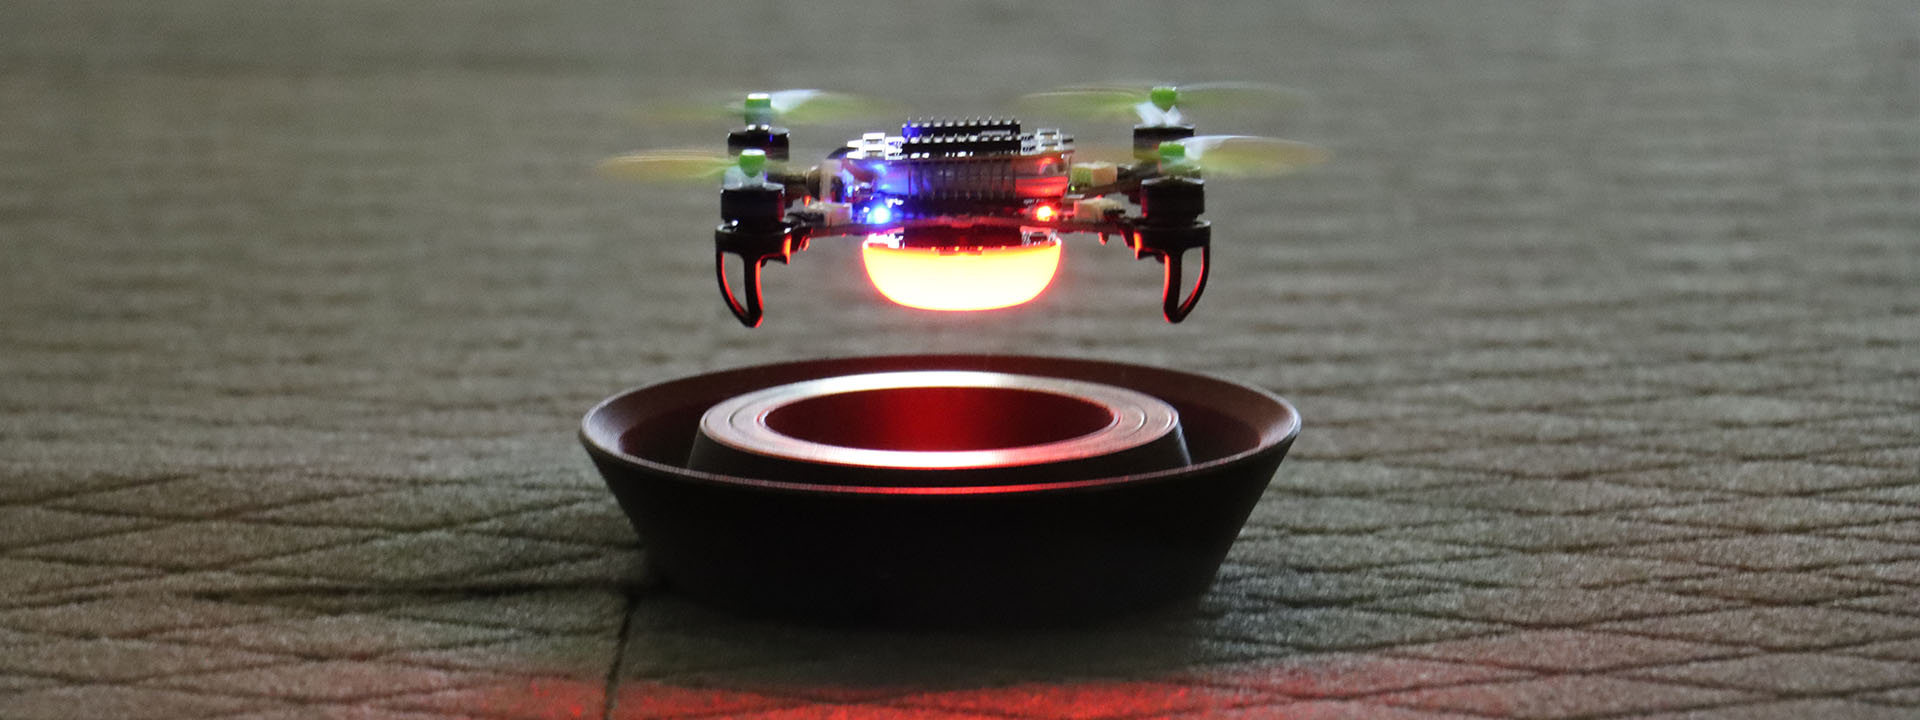
3 Brushless flying seen on a beige workplace background

Most research teams answer this question by writing custom coordination firmware specific to their experiment. The result works, but it does not transfer to the next experiment or the next platform. I wanted an answer that would.

Tapestry OS provides this layer as an open-source coordination stack built on Zephyr RTOS. It includes a distributed world model, gossip-based state propagation, fault-tolerant consensus, and a declarative application API that lets domain experts express collective behavior without touching the underlying firmware. This post is about porting Tapestry to the Crazyflie 2.1 Brushless and validating its core coordination claim on three drones flying in collective formation.

The port

Tapestry’s stack has seven layers, L1 through L7. For the Crazyflie port, the work lives in L1: the Physical Substrate Interface, Tapestry’s equivalent of a board support package. We began by developing a native Zephyr port for the Crazyflie 2.1 Brushless. This had to include the flight control itself: attitude (rate + angle), altitude-hold, position-hold loops, sensor drivers, and a Lighthouse V2 deck driver. Bitcraze stock firmware was an invaluable reference (the control cascade architecture and the Lighthouse calibration math especially) though Tapestry’s implementation is written from scratch and shares no code with it. 

Bring-up including L2 had some surprises, including two real bugs in Zephyr’s STM32 I2C driver that the Tapestry repository carries as patches until they are upstreamed. Streaming console output over the Crazyradio early in the port made debugging much less painful.

Lighthouse positioning took the longest. The interesting problems were pairing the base station’s sweep planes correctly from raw deck timestamps, and rejecting phantom rays from specular room reflections. The eventual implemented solution gates rays against the base station’s optical field of view (a hardware constant that survives recalibration) plus triangulation-consistency and rate-of-motion checks. Once resolved, position accuracy is solid.

Tapestry’s higher layers, including the L3 gossip transport and the L4 Collective State Manager, required no changes. That is the point: once the foundation is in place, the coordination logic does not care whether it is running on a ground robot or a drone.

The formation demo

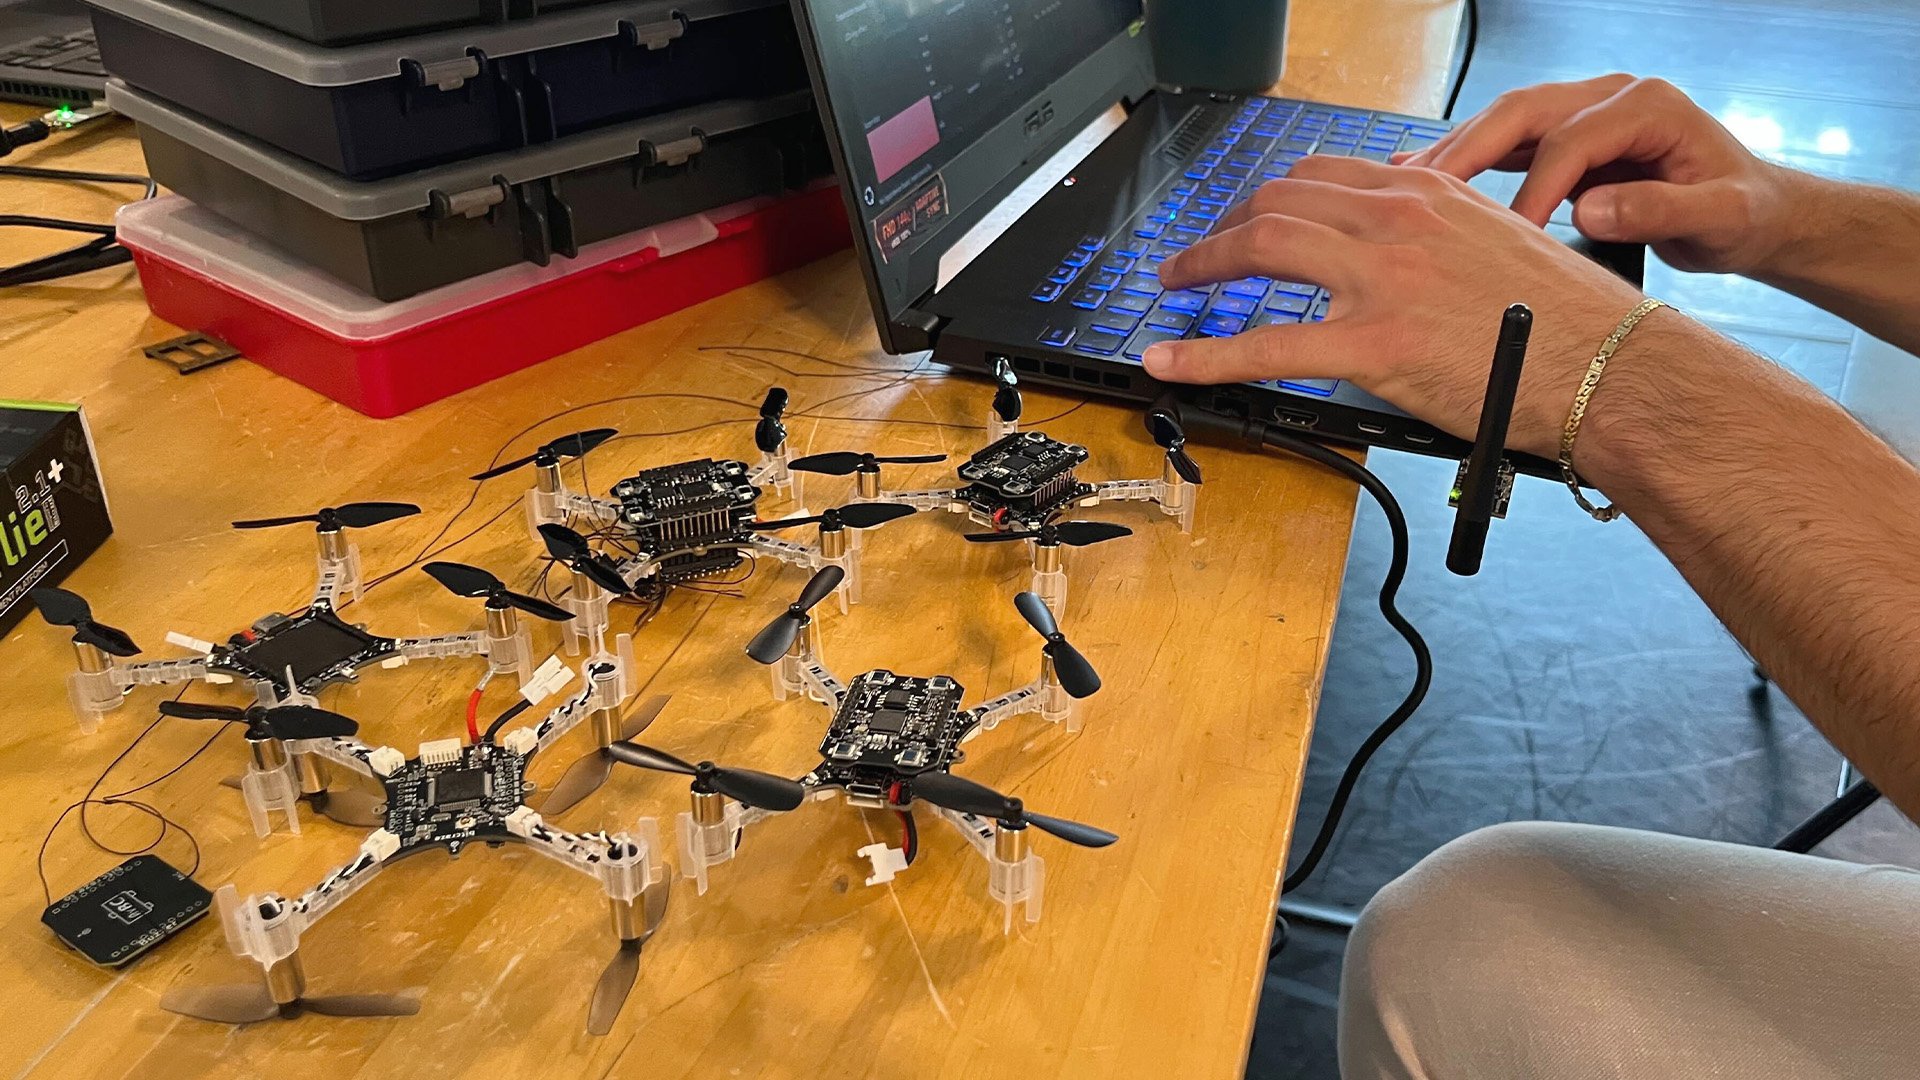
Three Crazyflie 2.1 Brushless drones, each running Zephyr with the Tapestry substrate and collective world model, were flown in a simple formation. Each drone reads its own absolute position from the Lighthouse deck and gossips it to its peers every 500 ms over the nRF51’s peer-to-peer radio channel. The resulting world model holds fresh entries for its two peers, with staleness tracking, and continually compares its distance to each fresh peer against a target spacing: too close pushes away, too far pulls closer. 

The example formation in the following video shows two drones hover and align in equilibrium. When a third powers on and flies among them, the three maintain separation until the third drone ends its mission, lands itself, and the remaining two close back into their line before landing.

There is no leader, no ground station, and no phase script: each drone runs Tapestry’s decentralized world model and shares only its own position over gossip. The recovery behavior is the part to watch closely. When one drone ends its mission, it lands and goes silent. The remaining two re-form their line about ten seconds after the departure, without any instruction from an external system. This is deliberately the same code path that would handle a real mid-flight interruption. 

This is Tapestry’s first demonstration on real Crazyflie drones: a coherent shared understanding of collective state, maintained entirely through peer-to-peer gossip, driving behavior through local rules. The demo logic can be expressed as a declarative L7 Choreo with the Tapestry SDK without touching firmware.

What is available

The Crazyflie 2.1 Brushless support is in the Tapestry OS repository under Apache 2.0. It includes the steps to recreate this demo: per-drone configuration, Lighthouse calibration, and ESC provisioning.

This is an initial port. We chose Zephyr to unlock a standardized, scalable ecosystem that allows the Crazyflie to integrate with industrial-grade RTOS tooling. We chose standard PWM for this port to simplify the initial Zephyr hardware abstraction with a stable and reliable baseline for our formation coordination logic. A number of Crazyflie capabilities are not yet available on the Zephyr-based stack (Kalman estimation, flow deck, and DSHOT among them), and contributions are welcome.

If you are doing swarm research on the Crazyflie and want coordination infrastructure you do not have to build yourself, the Tapestry repository is a good starting point. Try the port, open an issue if you hit hardware-specific bugs, and share your formation experiments on GitHub or in the Bitcraze forum.
At Bitcraze we really have a front-row seat in robotics research. Every week, various papers appear: Conference papers, PhD theses, journal articles, and preprints that resonate across the community. Sometimes they arrive from universities we’ve worked with for years, and sometimes from labs we’ve never heard of before.

We are constantly humbled by the possibilities and the lengths that the community takes the platform. Although applications seem endless, we’ve grouped recent papers from the community into broad categories to give a useful snapshot of how different labs and research groups are answering questions from different angles.

Swarms are all about robustness (and size)

A decade ago, entire keynote talks revolved around ever-larger choreographed formations. Don’t get me wrong, it’s always impressive to see large swarms, but recent papers seem to increasingly raise questions around reliability.

How do individual robots coordinate without overwhelming the communication network? What happens when information arrives late? What if one vehicle fails? How do you distribute decisions without relying on a central controller?

DMPC-Swarm: Distributed Model Predictive Control for Nano-UAV Swarms is a good example. Rather than treating coordination as a centralized optimisation problem, the authors investigate distributed model predictive control, with the optimization shared across the swarm rather than handled by a single central unit (see https://link.springer.com/article/10.1007/s10514-025-10211-w).

It’s also interesting to see how much current work still builds on the foundations laid by the original Crazyswarm framework (https://ieeexplore.ieee.org/document/7989376). Nearly a decade later, it continues to serve as a reference point for new ideas, while more recent work pushes towards larger, more resilient, and more scalable swarm systems (https://ieeexplore.ieee.org/document/10611499).

Flying robots are literally touching the world

The most common drone use case is still the observer. To inspect bridges, map forests, measure crops, and capture data, but aerial manipulation turns that idea upside down.

Instead of asking what a flying robot can see, researchers ask what it can do. Some groups investigate cooperative payload transport (https://ieeexplore.ieee.org/document/8461014). Others focus on cable manipulation and contact-rich interaction (https://ieeexplore.ieee.org/document/10382688). More recent work explores increasingly sophisticated manipulation strategies while maintaining stable flight (https://ieeexplore.ieee.org/document/10802794).

Aerial manipulation forces multiple disciplines together. Control theory, estimation, mechanical design, and physical interaction all become tightly coupled. As these systems mature, flying robots may increasingly move beyond sensing and inspection roles into applications that require direct interaction with the physical world.

The challenge of making AI practical

Look anywhere and everything’s “AI”, but thankfully the research papers tell a nuanced story. Researchers are asking practical questions, if learning can improve flight performance without sacrificing stability, if sophisticated controllers can run on tiny embedded processors, and if simulation can reduce the amount of expensive real-world data needed before deployment?

DATT: Deep Adaptive Trajectory Tracking explores how learned components can complement classical control methods under uncertain conditions (https://arxiv.org/abs/2310.09053).

Learning to Fly in Seconds takes another route, demonstrating how efficient training in simulation can dramatically shorten the path to successful real-world flight (https://ieeexplore.ieee.org/document/10517383).

Palossi et Al. investigates yet another line of research on how machine learning can be integrated directly into flight control, allowing nano-quadcopters to improve their performance while remaining reliable and computationally efficient (https://ieeexplore.ieee.org/document/8715489)..

The frontier isn’t simply making robots smarter. It’s making sophisticated autonomy accessible on hardware small enough to fit in the palm of your hand.

Can robots learn to work with people, not just around them?

Technical performance alone doesn’t determine whether a robotic system is successful. People need to understand what the robot is doing, communicate with it naturally, and develop enough confidence to work alongside it.

That has led researchers to investigate everything from gesture-based interfaces, or “SwarmTouch” (https://ieeexplore.ieee.org/document/8758191) to shared autonomy in Hand-worn Haptic Interface for Drone Teleoperation (https://ieeexplore.ieee.org/document/9196664) and broader questions around interaction and collaboration between humans and aerial robots bu La Delfa et Al. (https://ieeexplore.ieee.org/document/10973956).

In some cases, the hardest challenge is not controlling the robot itself, but designing the relationship between humans and machines. After all, even the most capable autonomous system ultimately exists to help someone accomplish something.

Sometimes the cleverest solution is the simplest one

Before a robot can make intelligent decisions, it must know where it is. For small aerial robots, this question is particularly challenging, since limited payload capacity restricts sensor choices, while limited onboard compute constrains what algorithms can realistically run. This has made nano-quadcopters an attractive platform for investigating efficient perception and navigation techniques.

In Visual Route-following for Tiny Autonomous Robots, published in Science Robotics, researchers demonstrated an insect-inspired navigation strategy using an omnidirectional camera mounted on a Crazyflie Brushless (https://www.science.org/doi/10.1126/scirobotics.adk0310).

Rather than constructing detailed maps of the environment, the robot simply learns visual routes and follows them. It’s an elegant reminder that engineering progress doesn’t always come from adding complexity, but from asking what can be removed.

That same philosophy appears elsewhere in recent perception and navigation research, where teams continue to develop increasingly efficient onboard perception and localization methods suited to the severe constraints of nano-quadcopters. NanoSLAM: Enabling Fully Onboard SLAM for Tiny Robots (https://ieeexplore.ieee.org/document/10343110, and Robust and Efficient Depth-Based Obstacle Avoidance for Autonomous Miniaturized UAVs are perfect examples of this (https://ieeexplore.ieee.org/document/10272390).

A community exploring difficult problems

What makes the broad body of Crazyflie research interesting is the sheer variety of approaches researchers bring to the same fundamental challenges. Across universities, laboratories, and disciplines, researchers continue to investigate cooperation, physical interaction, learning, perception, and human collaboration from different angles.

Taken together, these projects provide a glimpse of where robotics research is heading. There’s clearly more to find out, and we’re glad to keep being part of how people go looking.

Visit our Applications pages for more examples of how researchers, educators, and innovators are using the Crazyflie.

ICRA 2026 has wrapped up, and we’re back from a fantastic week in Vienna! Booth 91 was busy from start to finish, and we wanted to put together a short highlight video to share some of what happened — for everyone who stopped by, and for everyone who couldn’t make it this year.

The Swarm Demo

At the center of our booth was our live autonomous swarm demo — multiple Crazyflies flying autonomously in a controlled indoor environment, with everything tracked, repeatable, and stable across runs. We also could play around with our Lighthouse wand – which was also a great solution for troubleshooting the few misbehaving drones we had during those 3 days.

SwarmGPT, Live and Interactive

One of the highlights of the week was demonstrating SwarmGPT together with the Learning Systems and Robotics Lab (LSY) at the Technical University of Munich. SwarmGPT explores a simple but powerful idea: instead of hand-coding trajectories, you describe the intent — pick a piece of music, prompt a style or expression — and the system handles the planning and safety while the swarm performs it.

This time around, we brought a more interactive version of the demo than our end-of-year collaboration a few months back, and visitors got to try it out for themselves at the booth. Watching people prompt the swarm and then watch their idea come to life in the air was a great reminder of how far natural-language interfaces have come, and how much room there still is to explore in this space.

Research We Saw on the Crazyflie

Beyond our own demos, one of our favorite parts of ICRA is talking with our users and seeing what the community has built. This year was no exception — we spotted Crazyflies appearing in research spanning multi-agent coordination, modular micro-UAVs designed for autonomous mid-air docking, and decentralized swarm control approaches where each drone makes its own decisions based on local information rather than a central planner. Some examples include:

It’s always a bit surreal to see the same small quadcopter we ship from our office end up at the center of such different research questions — from choreography and language-driven control, to docking and modular hardware, to fully decentralized swarms. If you presented work involving the Crazyflie this year, thank you for stopping by and sharing it with us — and if you left a poster behind, it’s already found a home on our office wall.

Thanks for Stopping By

ICRA continues to be one of our favorite events of the year, not just for the demos, but for the conversations. Someone describes a challenge they’re running into in their lab, and a few months later, that conversation has often turned into a feature, a library improvement, or a new piece of hardware. If you stopped by booth 91, told us about your research, or just said hello, thank you. We’re already looking forward to the next one!

If you’d like to dig deeper into any of what’s shown in the video, or want to get started with the Crazyflie yourself, head over to bitcraze.io or reach out at contact@bitcraze.io.

We built a small drone for people who want to understand how things fly. The community took it considerably further than that. The citations keep arriving from directions we didn’t anticipate. Spacecraft dynamics. Tactile human-swarm interaction. Onboard deep learning. Mapping algorithms that fit inside a nano-drone’s compute budget. The platform’s combination of openness, known dynamics, repeatable behavior, and low replacement cost turns out to be useful for a wider set of problems than any single team could have imagined building for.

What follows is by no means a comprehensive survey, but rather a selection of research areas where the Crazyflie has found a home, each illustrated with recent work. We find it genuinely interesting that the same hardware can be useful across this range, and we hope it gives other researchers a sense of what is possible.

1. Decentralized Multi-Agent Coordination and Swarm Control

Multi-agent coordination is probably the research area most closely associated with the Crazyflie, and for good reason. The platform’s light weight, predictable dynamics, and relatively low cost per unit make it practical to run experiments with enough agents to observe emergent swarm behavior, rather than just simulating it. A lab can field a meaningful swarm without the capital outlay that larger platforms would require.

Recent work has pushed this in some interesting directions. Decentralized approaches, where each agent makes decisions based on local information rather than a central planner, are particularly well-served by a platform where individual failures don’t cascade into catastrophic system loss. Research on collision avoidance, formation control, and consensus algorithms benefits from hardware that can absorb the crashes that inevitably happen when you are testing novel coordination strategies.

See “Design and Implementation of EPM Based Modular Micro-UAVs for Autonomous Midair Docking” IEEE paper (11248819) for an example of custom hardware extending with the Crazyflie.

The ROS 2 ecosystem around the Crazyflie has matured considerably, with frameworks like Crazyswarm2 enabling standardized multi-drone experiments that other labs can replicate. The reproducibility this enables is meaningful: a coordination result demonstrated on Crazyflies in one lab is demonstrable in another (see “CrazyChoir: Flying Swarms of Crazyflie Quadrotors in ROS 2” (arXiv)).

2. Onboard AI and Edge Inference at Nano Scale

What can you fit inside a couple of dozen grams grams and still have compute left over for intelligence? Quite a lot, it turns out, especially when researchers are motivated to find out. The AI Deck, which adds a GAP8 system-on-chip with a camera and Wi-Fi, opened a wave of work on fully onboard perception and inference pipelines on nano-UAVs.

Researchers at ETH Zurich demonstrated autonomous visual navigation along a 113-meter previously unseen indoor path using a convolutional neural networkl (CNN) running at 18 Hz on the GAP8, without any external computation (see “An Open Source and Open Hardware Deep Learning-powered Visual Navigation Engine for Autonomous Nano-UAVs” (arXiv)

More recently, work using custom expansion decks with the GAP9 processor has enabled onboard SLAM and scan-matching at take-off weights around 46 grams, showing that the platform’s expansion architecture makes it a meaningful target even as compute capabilities grow. See “Ultra-Lightweight Collaborative Mapping for Robot Swarms” (arXiv).

The Crazyflie’s transparent hardware design is important here: researchers can build custom decks, verify the power budget, and integrate new silicon without waiting for a vendor to offer an approved configuration.

3. Spacecraft and Orbital Dynamics Simulation

Researchers at the University of Houston, in collaboration with the US Air Force Research Laboratory, used Crazyflie drones to simulate the relative motion dynamics of spacecraft in formation, specifically the Clohessy-Wiltshire equations that describe how objects move relative to each other in near-circular orbit.

The reasoning is practical: testing spacecraft autonomy on-orbit is expensive and high-risk. Ground-based testbeds using air bearings exist, but are complex and space-intensive. A small fleet of Crazyflies, running scaled versions of orbital trajectories in an indoor lab, offers a much cheaper and more accessible way to validate formation-flying control laws and neural network guidance systems before committing to hardware that will be launched into space.

The paper notes exactly why the Crazyflie was chosen: it is affordable, open source, readily available, and the expansion deck ecosystem provides positioning, sensing, and even AI capabilities that can be configured to match a specific experimental requirement (see “Testing Spacecraft Formation Flying with Crazyflie Drones as Satellite Surrogates” (IEEE)).

4. Reinforcement Learning: From Simulation to Real Hardware

Reinforcement learning (RL) for drone control has been a thriving research area for years, but the gap between simulation and physical hardware remains a hard problem to close. The Crazyflie’s well-documented dynamics, consistent manufacturing, and open firmware have made it a preferred target for sim-to-real transfer research, because the sim and the real thing can be brought into close agreement.

Work in this space spans a wide range of problem settings. Multi-agent RL for collision-free navigation, safe RL with control barrier functions, landing on moving targets, and agile trajectory following in cluttered environments have all been demonstrated on Crazyflie hardware. A common thread is that the platform’s low inertia and predictable response make it a fair test: there is nowhere to hide on a platform this light and responsive, and if the policy is sloppy, it falls (see AttentionSwarm: Reinforcement Learning with Attention Control Barier Function for Crazyflie Drones in Dynamic Environments” (arXiv).

The “LEARN framework”, which claims to run a compact attention-based RL policy on six Crazyflies for multi-robot navigation through 0.2-meter gaps at 2 m/s, is a recent example of how far this line of work has come. The system runs fully onboard, using only time-of-flight sensors, and transfers directly from simulation to real hardware without fine-tuning. See “LEARN: Learning End-to-End Aerial Resource-Constrained Multi-Robot Navigation” (arXiv).

5. Human-Swarm Interaction and Expressive Robotics

An unexpected corner of the research community is the one that adopted the Crazyflie to the human-robot interaction field. It turns out that a swarm of small, quiet, slow-moving drones is a better vehicle for studying how humans interpret and respond to group robot behavior than many ground robot alternatives.

Work in this space ranges from the technical to the almost philosophical. Researchers have studied whether humans perceive swarm motion as intentional and communicative; whether vibrotactile feedback can give operators an intuitive sense of swarm state during physical interaction; how flight formation shapes emotional perception; and how to design impedance-controlled swarms that respond naturally to human touch (see “SwarmTouch: Tactile Interaction of Human with Impedance Controlled Swarm of Nano-Quadrotors” (arXiv).

The Crazyflie’s low injury risk in the event of a collision, its predictable behavior, and its ability to carry sensing and communication payloads make it well-suited to user studies where physical proximity and spontaneous human response are important variables. The fact that the platform is widely available also matters: HRI research benefits from results that can be reproduced in different lab environments with different participant populations.

See “Demonstrating How to Train Your Drone” IEEE paper (10973956) for an example of humans shaping interactions with drones.

A Note on What Makes This Possible

Looking across these five areas, a pattern emerges. In each case, the research is not about the Crazyflie itself. The platform is a means, not an end.

What the Crazyflie provides is a credible physical substrate that researchers can trust to behave consistently, modify freely, and replace cheaply when something goes wrong. The open source firmware means the dynamics are fully inspectable. The transparent hardware means the platform can be extended with custom decks. The stable software ecosystem means results from one year’s experiments can be compared against another year’s, and against results from other labs using the same platform.

If your research uses the Crazyflie in a direction not represented here, we’d like to hear about it. The research portal at bitcraze.io/portals/research lists some of what we know about, but the community is larger and more inventive than any curated list can capture.

It’s that time of year again! ICRA 2026 (IEEE International Conference on Robotics & Automation) is just around the corner, and this year we’re heading to Vienna. We couldn’t be more excited about this one: Vienna is an incredible city, and we’ve been working on some things we can’t wait to share.

June 1–5, 2026. Come find us!

A reproducible testbed for aerial robotics research

We will be running a live autonomous flight system based on the Crazyflie platform.

The focus is not the flight itself, but what it enables. The system provides a controlled indoor environment where experiments can be repeated, variables isolated, and results compared over time.

This is aligned with how aerial robotics research is actually conducted: iteration speed, reproducibility, and observability matter more than scale in early and mid-stage research. Our platform is designed around those constraints.

Autonomous indoor flight for controlled experimentation

The setup demonstrates autonomous flight under conditions that remain stable across runs.

This allows researchers to evaluate control strategies, perception pipelines, and multi-robot coordination without environmental noise dominating results. It also reduces costs and operational overhead compared to larger platforms, which changes how frequently experiments can be run.

In practice, this makes it feasible to move from idea to validated result faster and with clearer insight into failure modes.

Used in swarm robotics, control, and physical AI research

The Crazyflie platform is used across domains such as swarm robotics, learning-based control, SLAM, and human–robot interaction.

It has been referenced in hundreds of peer-reviewed publications and is often used as a bridge between simulation and larger systems. The value is not in representing the final deployment environment, but in enabling rigorous, comparable experimentation at low cost and risk.

If you are working in these areas, we are interested in how your setup is structured and where constraints appear.

Share your work with us

If you are presenting work that involves the Crazyflie, we would like to see it.

Even better, if you do not need your poster after your session, bring it by the booth! We collect and display these as part of the broader body of work built on the platform. We will make sure it is appreciated properly.

Meet us at ICRA 2026

One of our favourite things about ICRA is getting to meet the community in person, hearing about your research, seeing what you’ve built with the Crazyflie, and exchanging ideas with people who are just as excited about small flying robots as we are. Whether you want to chat about your research, see the demo up close, or just catch up, our booth is the place to be. We love hearing about all the cool projects you’re working on with the Crazyflie, so don’t be shy!

If you are working with the Crazyflie, evaluating platforms, or exploring new research directions, stop by booth 91. You can also reach out at contact@bitcraze.io to schedule time.

Today, we welcome our first blog post by Maurice Zemp. Stay tuned for more of his adventures later!

When I started working on my Matura thesis (a mandatory project in Swiss High School), I wanted to create something that went beyond a purely theoretical project. I was fascinated by the idea of combining cutting-edge technology with a very tangible and exciting challenge: making a small drone fly through a racing course, composed by small gates, completely on its own and as fast as possible. Inspired by the work under Prof. Davide Scaramuzza, I set off for a challenge to find some new alternatives or improvements, while developping my approach from scratch.

What may sound simple at first quickly turns into a highly complex task. A drone needs to perceive its environment, process information in real time, and decide on precise actions within fractions of a second, all without human intervention. Professional drone racing pilots train for years to master this level of control. My goal was to see whether artificial intelligence could achieve something similar, using reinforcement learning as the core technique.

But there was another challenge: I wanted to design a system that wasn’t only powerful, but also affordable and reproducible. Many research institutions use equipment worth tens of thousands of francs for projects like these. I asked myself: Could I build something comparable with a fraction of the budget, and still push the boundaries of what’s possible?

That question became the driving force behind my project, which later brought me all the way to the finals of Schweizer Jugend forscht (short SJf) and saved me a place as the main prize to represent Switzerland at the world’s biggest Youth Science Competition, ISEF 2026. Over the following sections, I’ll share how I built my system step by step, what it was like to present it at the competition, and how it felt when all the effort finally paid off.

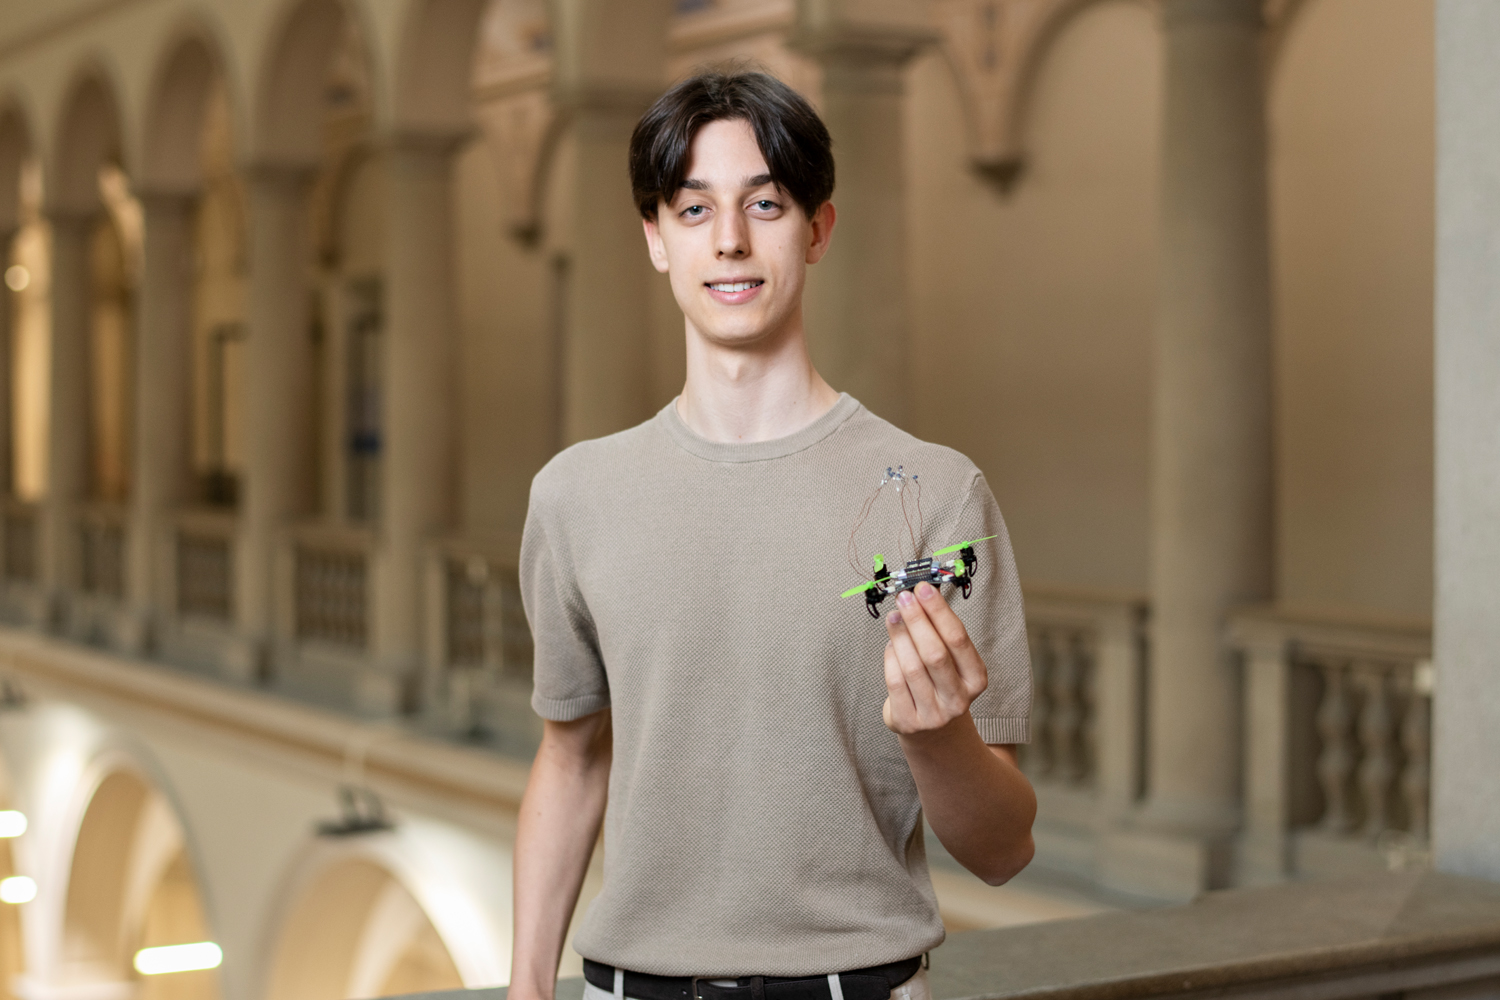
Fig. 1: Me with the Crazyflie 2.1 Brushless in the halls of ETH Zurich, where the main event of SJf took place.

Motivation and Objectives

The project I presented at Schweizer Jugend forscht was the result of my Matura thesis, in which I set out to combine my interests in drones, programming, and artificial intelligence. My goal was to develop a complete system for autonomous drone racing, based on Reinforcement Learning (RL), that would not only work in simulation but could also be transferred to real-world conditions.

To achieve this, I focused on three key aspects:

  1. Building a highly efficient simulation environment for training a reinforcement learning agent.
  2. Developing a cost-effective motion-capture system (MoCap) capable of tracking a drone’s position and orientation in real time with high precision.
  3. Integrating both systems in a way that would allow seamless transfer from simulation to real-world experiments with minimal latency.

This combination made the project unique: instead of relying on expensive commercial hardware, I set out to create a solution that would be precise and affordable but still continue the state-of-the-art development in Drone Racing.

Simulation Environment

The simulation was implemented in Python, using Stable Baselines, OpenAI Gymnasium, and NumPy, accelerated with Numba for performance. At its core, the system employed the Proximal Policy Optimization (PPO) algorithm, a state-of-the-art reinforcement learning algorithm known for stability and efficiency.

Unlike general-purpose simulators such as Gazebo, my environment was designed specifically for drone racing. It could process tens of thousands of interactions per second, enabling a training run of a few dozen minutes to correspond to nearly a year of simulated flight time.

Key features included:

  • A physics-based flight dynamics model accounting for thrust, drag and gyroscopic effects.
  • A carefully engineered reward function balancing speed, precision and avoiding shortcuts.
  • A flexible design that allowed different gate sequences and drone parameters to be tested.
  • A multi-agent environment computing on multiple threads, leading to much shorter training time needed.
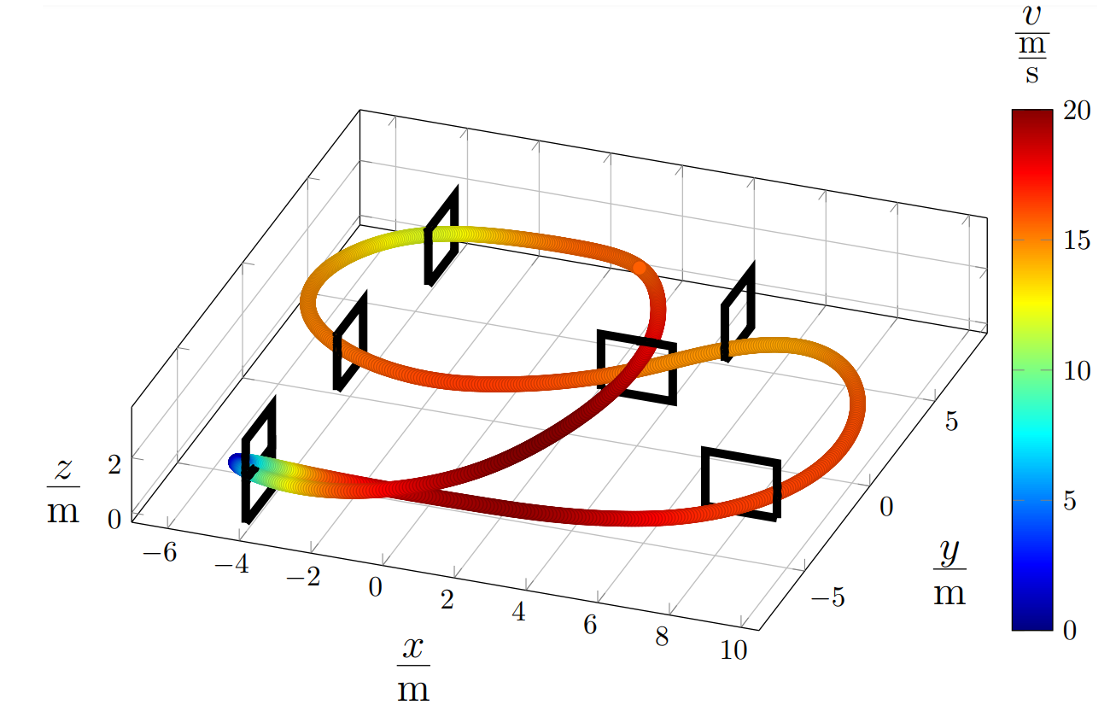
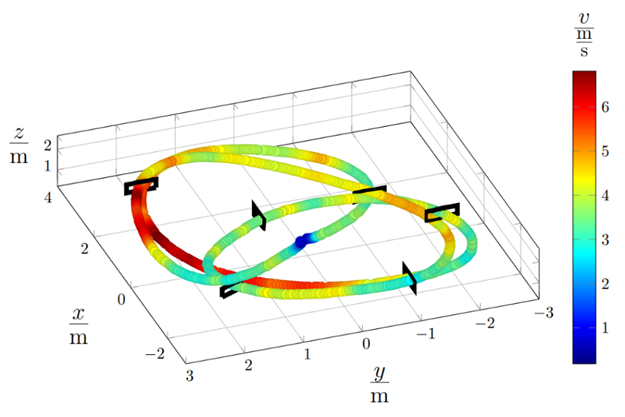
Fig. 2: Path of the drone after two hours of training on a given track

With this setup, an RL agent could learn to complete arbitrary racing tracks in near-optimal time1 after only a few hours of training. In simulation, top speeds of up to 100 km/h were achieved, though these exceeded the physical limits of the real drone and were generated with modified drone parameters.

Motion-Capture-System

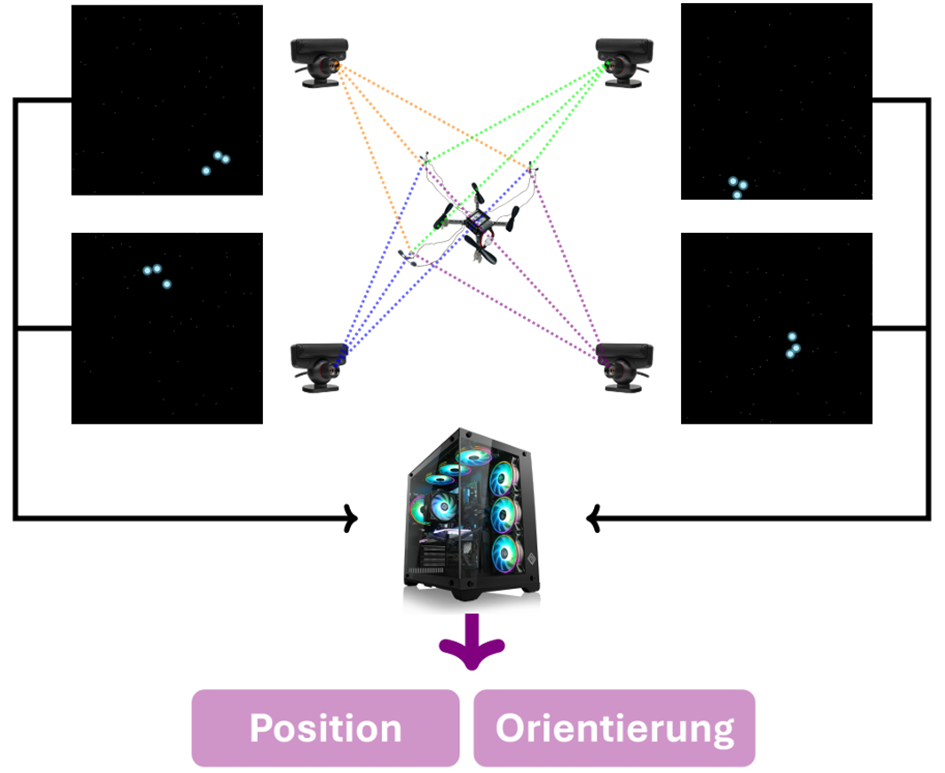
A second cornerstone of the project was the development of a low-cost motion-capture system. Instead of relying on high-end solutions such as VICON or OptiTrack (which can cost tens of thousands of Swiss francs), I built a custom setup. The drone – a Crazyflie 2.1 Nanocopter (later a Crazyflie 2.1 Brushless) – was fitted with infrared diodes. With four cameras capturing at 120 frames per second, the drone’s position was calculated in real time through triangulation. By using three diodes arranged on the drone, I not only wanted to estimate the position but also the orientation. Unfortunately, due to the cameras being budget and thus not having a high-end resolution, the estimation of the orientation was not feasible and was therefore taken from the onboard IMU.

Fig. 3: Motion-Capture-System Concept

System Integration

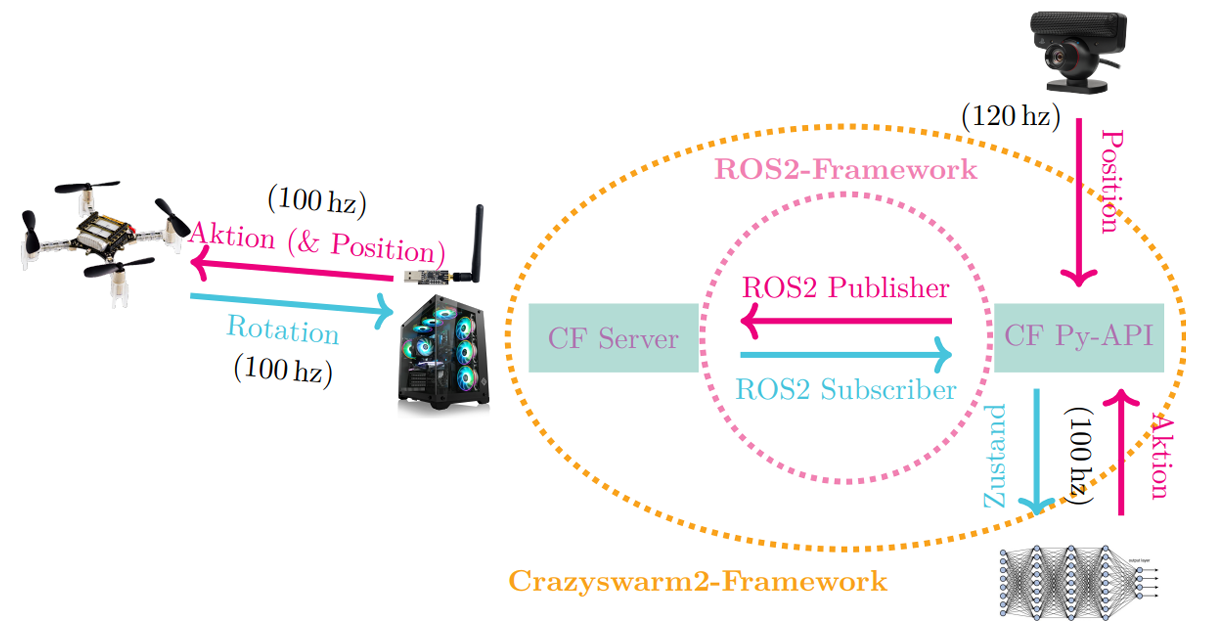
For integration, I relied on the ROS2 middleware and the Crazyswarm2 framework, which allowed the simulation and MoCap data to be processed together with minimal latency. This setup ensured that a policy trained in simulation could be executed on the real drone almost seamlessly.

Fig. 4: Sim2Real Integration Concept

Results & Discussion

The results demonstrated the effectiveness of the combined system:

  • In simulation, the RL agent completed tracks in nearly optimal time1, demonstrating robust generalization across different gate sequences.
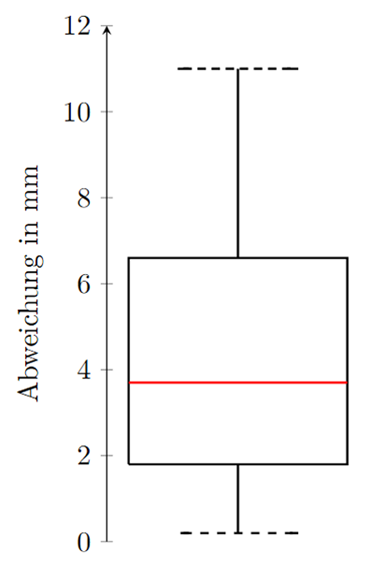
  • The motion-capture system delivered millimeter-level accuracy and reliable tracking in real time despite its simplicity. (see Fig. 5)
  • In real-world tests, the Crazyflie drone successfully completed tight gate sequences, even at speeds of up to 25 km/h, with a positional deviation of only 5–12 cm compared to the simulated trajectories. (see Fig. 6)

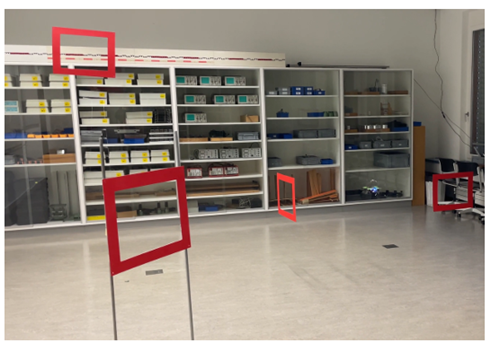
Given that the gates were roughly A3-sized openings (38 × 29 cm), the precision was sufficient to consistently hit every gate, confirming the feasibility of transferring simulated training into real-world racing. (Video)

Fig. 5: Boxplot of the deviation for collected points on a plane in millimeters
Fig. 6: Tracked Real Life Path on a given track
Fig. 7: Realisation in my school’s physics laboratory

The system demonstrated that RL-based controllers can generalize effectively from simulation to reality, even with imperfect models. This robustness shows that RL is promising for real-world robotics applications where exact physical modeling is difficult or costly. To further investigate this robustness, I conducted ablation studies in simulation focusing on aerodynamic drag, as well as analyses of the MoCap system’s accuracy in measuring dynamic motion.

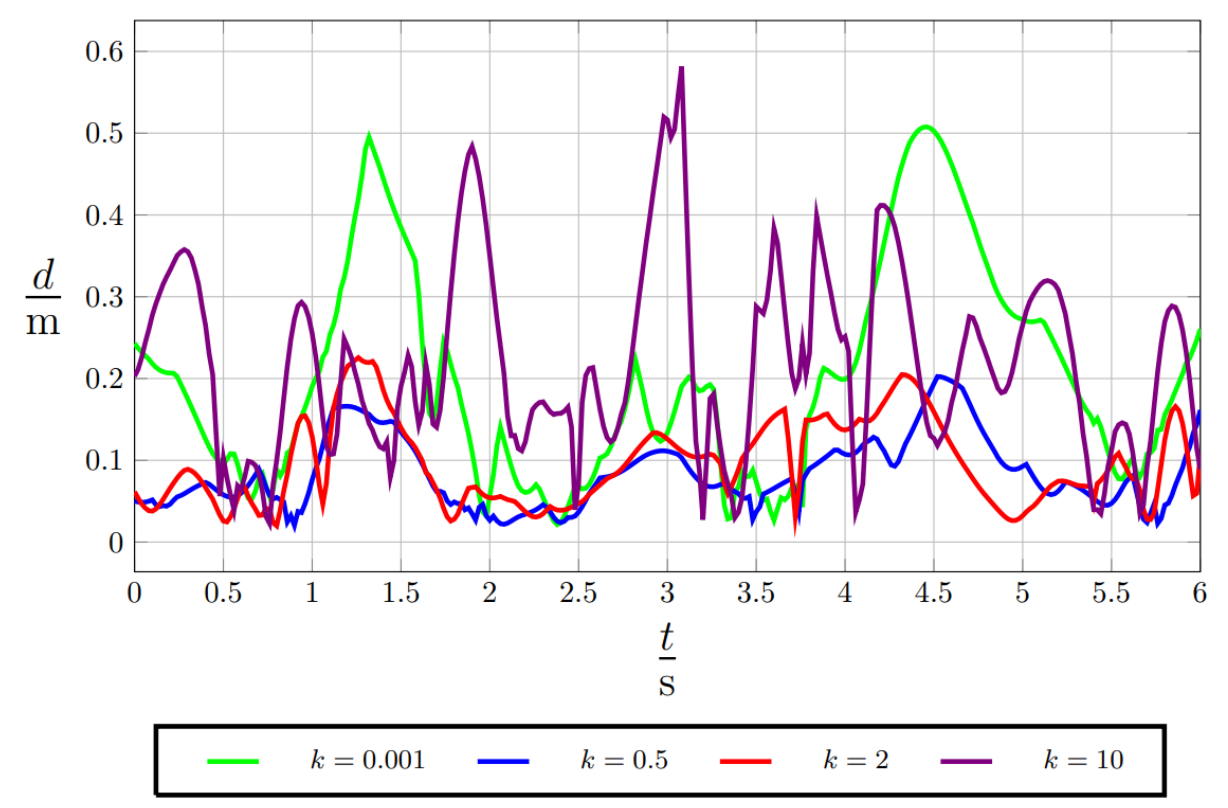
  • As for the aerodynamic drag, I introduced some randomness during evaluation, which deviated largely from what the Algorithm had trained upon. To achieve this, I introduced a parameter k which was multiplied with the correct aerodynamic drag to view how these differences would impact the flight. In Fig. 8 you can see the deviation from the real path over the course of a flight. As obviously more drag results in lower velocities, the two paths had to be fitted using the nearest two possible points. The results are impressive, even with an enormous change to training such as k = 10 the flight still performed somewhat okay, even though the gates probably wouldn’t have been hit anymore.
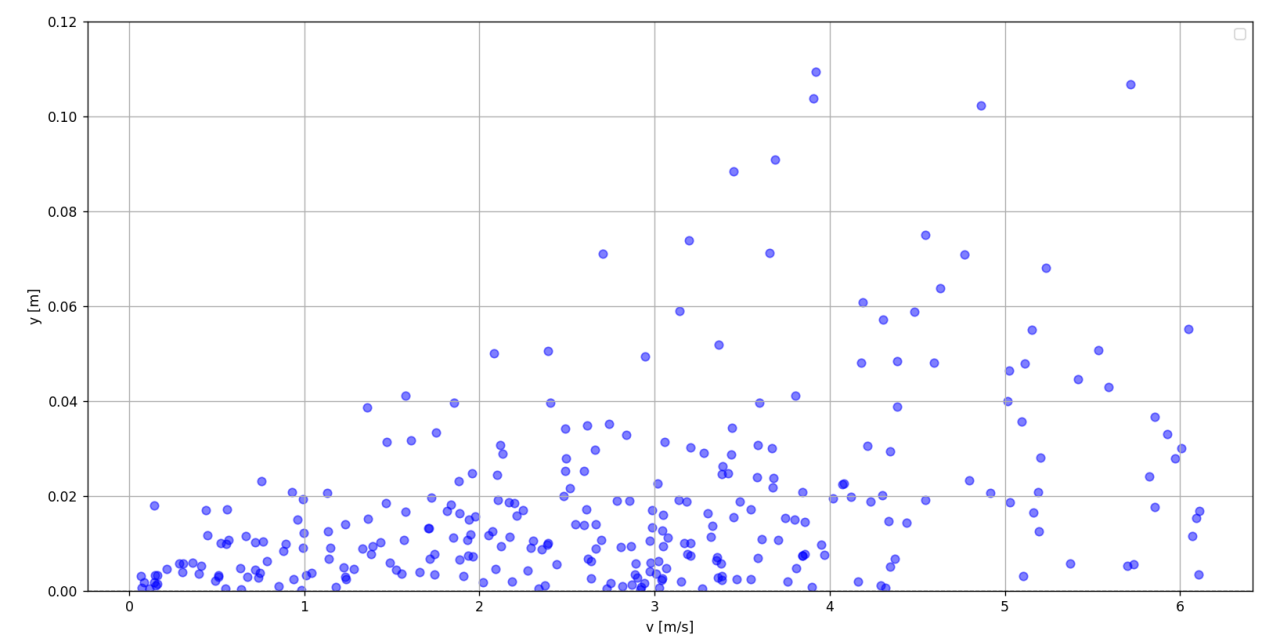
  • For the MoCap System, I used a mathematically representable motion, such as a pendulum. Then I performed a parameter optimization on this mathematical model and measured the deviation based on the current speed. There is a clear correlation between speed and deviation (see Fig. 9), which most likely was caused by the missing calibration of the cameras.
Fig. 8: Results of ablation studies on aerodynamic drag
Fig. 9: Experiment to confirm correlation between deviation and speed

Conclusion and Reflection

This work demonstrates that RL, combined with accessible hardware, enables precise and robust autonomous flight in dynamic indoor environments. The results underscore the potential of low-
cost robotics solutions to democratize drone research. Even though it was a large project and there were some hard times, I enjoyed working on it a lot and believe that the result and the memories made with it are even more rewarding than any prize money!

Acknowledgments

To end this guest post, I want to sincerely thank Bitcraze for their amazing work and support during the development of this project. They have genuinely built such an incredible testbed for research in autonomous drones, it’s amazing! Without them, this project wouldn’t have worked out the way it did!

  1. Near-optimal time here references to the theoretical boundary of a drone completing this track, given it’s parameters. To be clear, this is not fitting a polynomial with boundaries on their derivatives onto gate segments, as it was done during earlier approches in the 2010s. It was compared to multiple previous approches by UZH RPG such as Optimal Control (OC). Nevertheless, this comparison could be done more extensively in the future, as time ran short in the end. ↩︎

Guest post by Dominik Grzelak, Dresden University of Technology, Germany

This blog post accompanies a research article published in the XR Salento 2025 proceedings (Springer LNCS).

Setting up a mobile indoor positioning system with the Crazyflie platform—specifically using the Loco Positioning System (LPS)—typically involves walking through a large room with a laser measure, sticky notes, and a bit of patience.

That was exactly my situation at work when setting up UWB anchors for mobile robot demonstrations, which often had to be relocated to different rooms.
And it got me thinking—what if there were a more intuitive, flexible way to define and deploy these setups, especially in labs or educational settings where reconfigurability is key?

This question led to the development of XR-PALS, a mixed reality tool that simplifies the entire LPS configuration process.
Instead of manually measuring anchor positions and inputting coordinates into cfclient, XR-PALS allows users to create and sync virtual and physical setups almost seamlessly—just by moving virtual anchors in space using a VR headset.

Diagram showing the three-step setup for the Bitcraze Loco Positioning System: 1) Connect anchors, 2) Configure the system, 3) Track the Crazyflie drone in 3D space.
Three-step setup process for the Bitcraze Loco Positioning System, illustrating anchor connection, system configuration, and 3D Crazyflie drone tracking.

What is XR-PALS?

XR-PALS (XR-Powered Assistance for Loco Positioning Systems) is a tool we (Victor Victor and Dominik Grzelak) developed for defining cyber-physical spaces using UWB anchors on tripods.
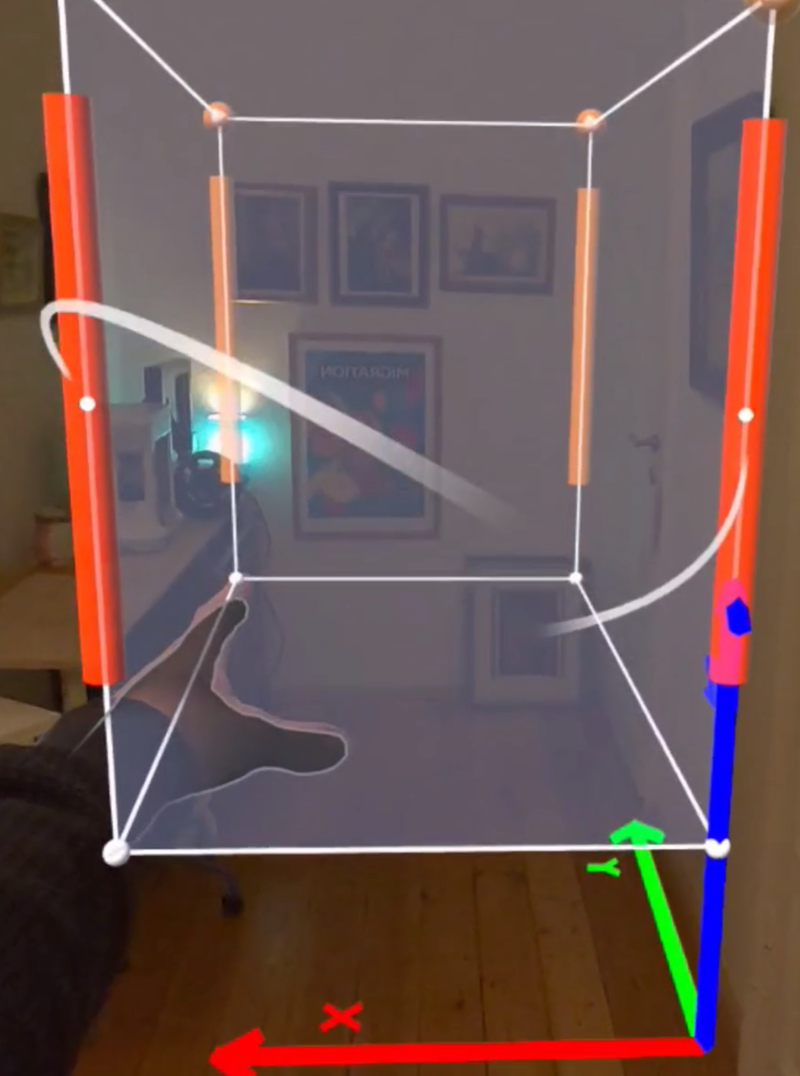
It runs on a passthrough VR headset (we used Meta Quest 3), allowing users to visualize the LPS layout and manipulate anchor placements in a virtual 3D environment until they are virtually and physically aligned.

Once everything is aligned, a single tap on the “Export” button sends the virtual anchor positions to a Rust-based middleware service running on a host machine within the same network as the VR headset.

It’s fast, visual, and eliminates the need for hand-measuring coordinates for our mobile robot demonstrators.

You can watch the system in action in our demo video:

Why We Built It

Usually, the LPS setup involves manual measurements and manual data entry in cfclient.
This is time-consuming when environments change frequently—as is often the case in education and research.

With XR-PALS, the goals are to:

  • Speed up setup – Users in our study completed setups significantly faster.
  • Reduce error – Anchor placement is visual and interactive. No calculations needed.

How It Works

XR-PALS consists of two main components:

  1. VR application
    Runs on a VR headset and displays the full anchor layout. Users can drag anchors, view distances, toggle info layers, and adjust alignment using natural hand gestures.
  2. Middleware service
    A Rust-based REST API that basically bridges the VR app with the LPS anchors. This service receives the coordinates and remotely updates the LPS anchors—enabled by the open-source nature of the LPS firmware: bitcraze/lps-node-firmware. Coordinates are exported as YAML that can be imported by cfclient.
Diagram showing the system architecture for the XR PALS setup, including UWB anchors, Crazyflie drone, tracking system, and XR interface components connected through data and control flows.
System architecture.
Images of XR PALS user interactions, showing a person wearing an XR headset controlling a Crazyflie drone in a physical space with visual overlays and positional feedback.
User interactions.

Real-World Evaluation

We compared XR-PALS against a traditional laser measurement tool in a user study involving 18 participants from our Faculty of Computer Science.
Each participant had to configure a LPS layout (trapezoidal or rectangular) using one of the two tools.

Results:

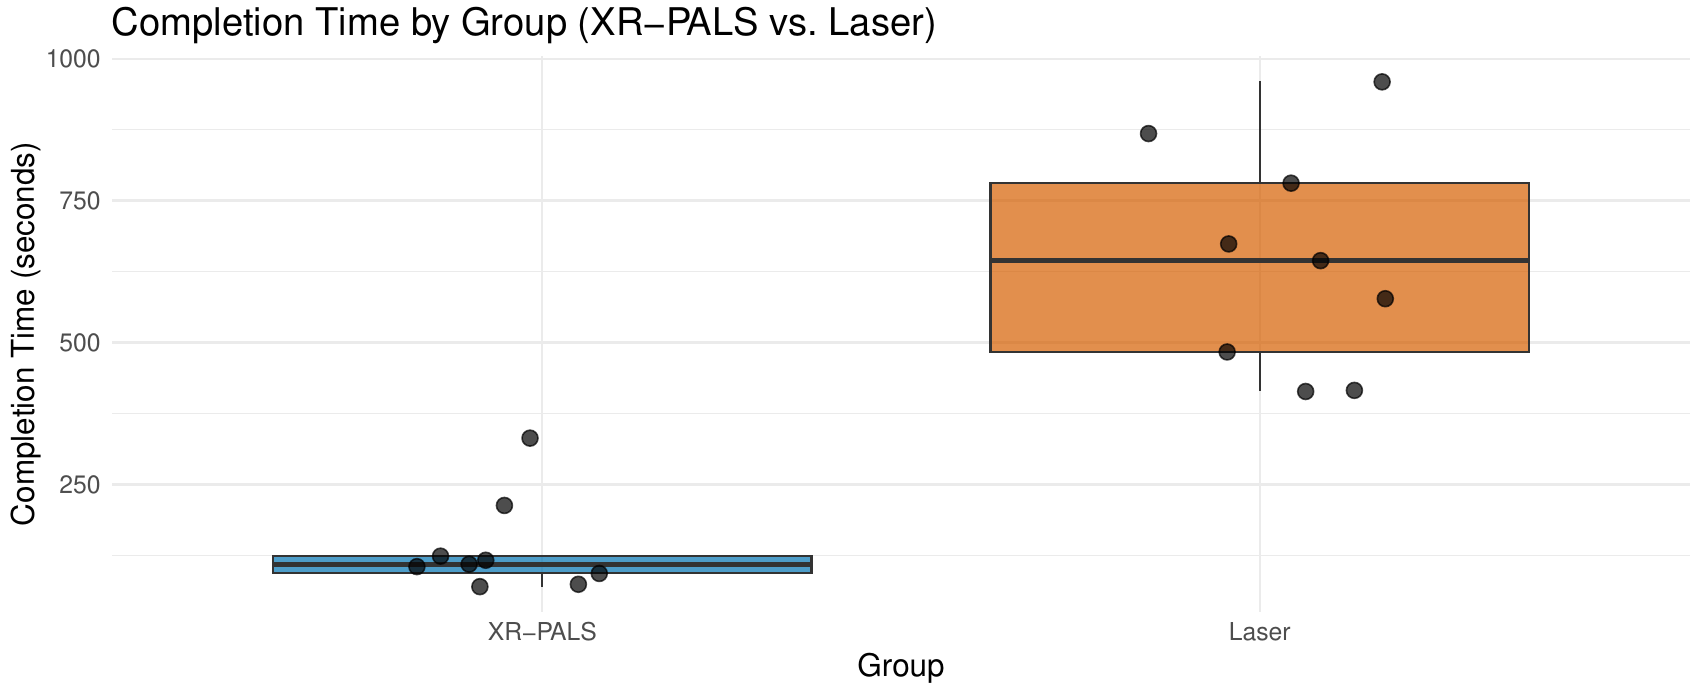
  • XR-PALS users completed the task faster
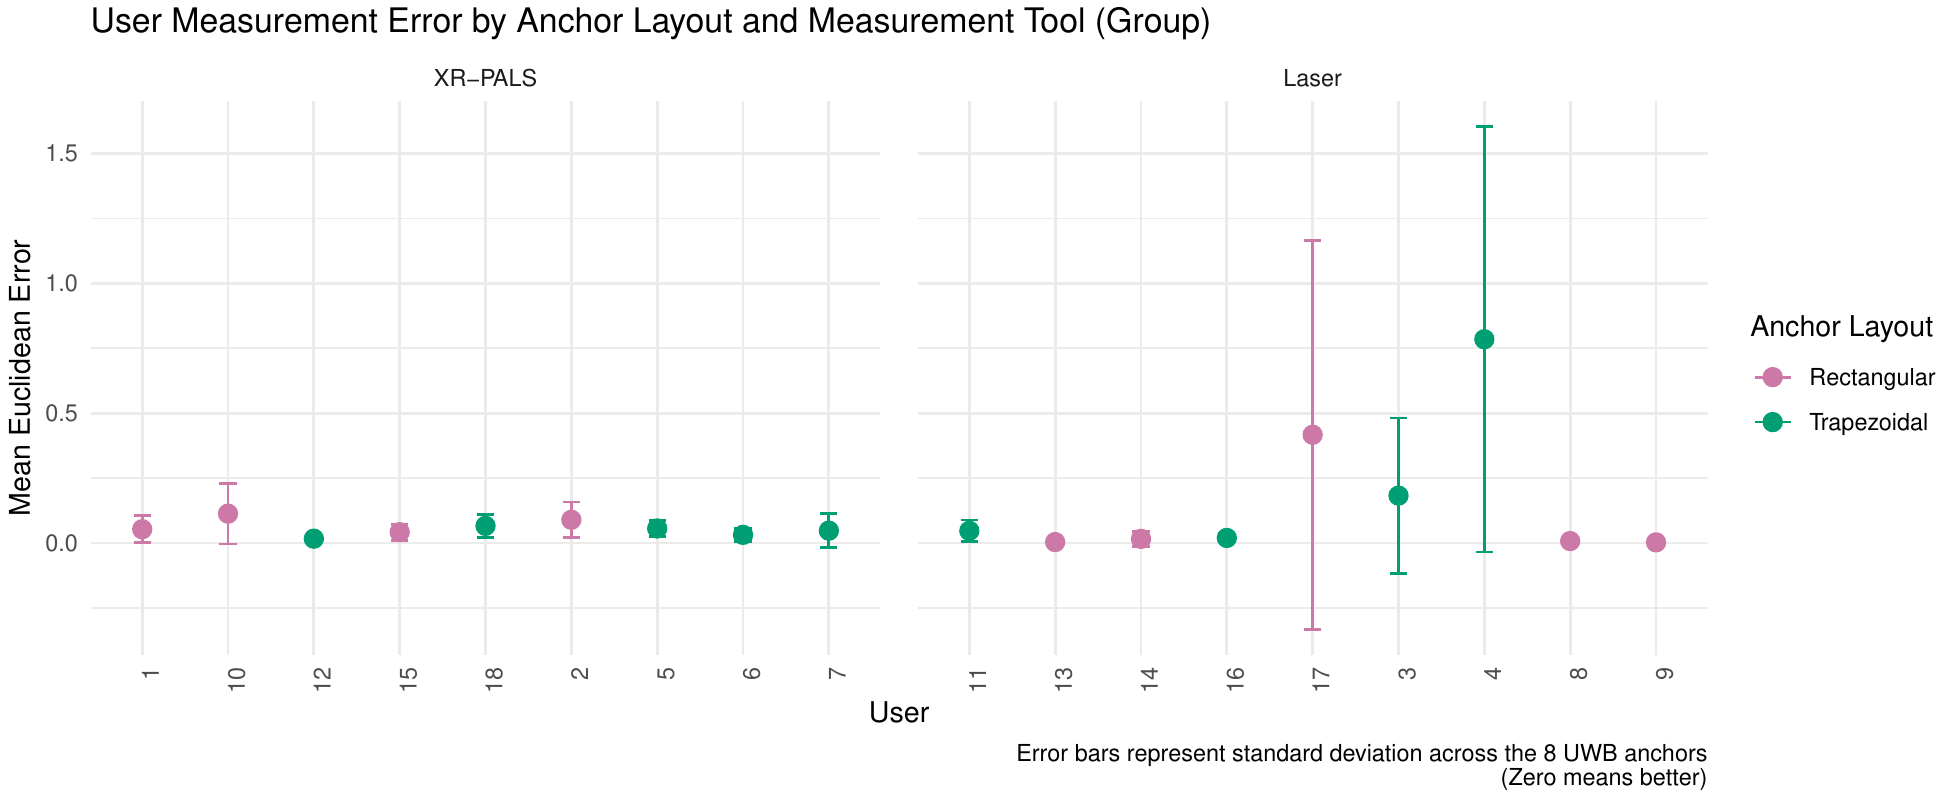
  • Fewer measurement errors
  • Higher usability scores and confidence
  • Lower cognitive load, especially for the trapezoidal layout
Bar chart comparing average task completion times for XR-PALS and laser methods, showing XR-PALS with shorter times. Lower values indicate better performance.
Bar chart comparing task completion times between XR-PALS and laser. Lower values are better.
Bar chart comparing average measurement errors for XR-PALS and laser methods, showing XR-PALS with lower errors. Lower values indicate better accuracy.
Measurement error comparison between XR-PALS and Laser. Lower values are better.

The minimal loss in accuracy compared to the time saved is not dramatic for our use cases, compared to the time saved—especially when more participants were able to correctly determine the coordinates overall.
In general, users were more confident using VR glasses than a laser measurement device.

Summary and What’s Next

So if you’re working with dynamic robot setups or swarm experiments, XR-PALS might save you a lot of setup time.

The app works natively with the Bitcraze Loco Positioning System and, so to speak, extends the capabilities of the cfclient.

Here’s what we’re currently thinking about:

  • Supporting larger anchor sets within the app (currently limited to 8 anchors)
  • Improving user interactions based on feedback from our user study
  • Displaying anchor diagnostics (e.g., latency, power levels)
  • Simpler layout reusability (layouts can be saved and shared only via the computer)
  • Adding support for LPS-ROS
  • Releasing the Code here
  • Better casing and docking solutions for the nodes (3D printing)

Check out the project page for updates—and feel free to reach out if you’d like to share how you’re using the LPS.


UAV Recharging for Remote Applications

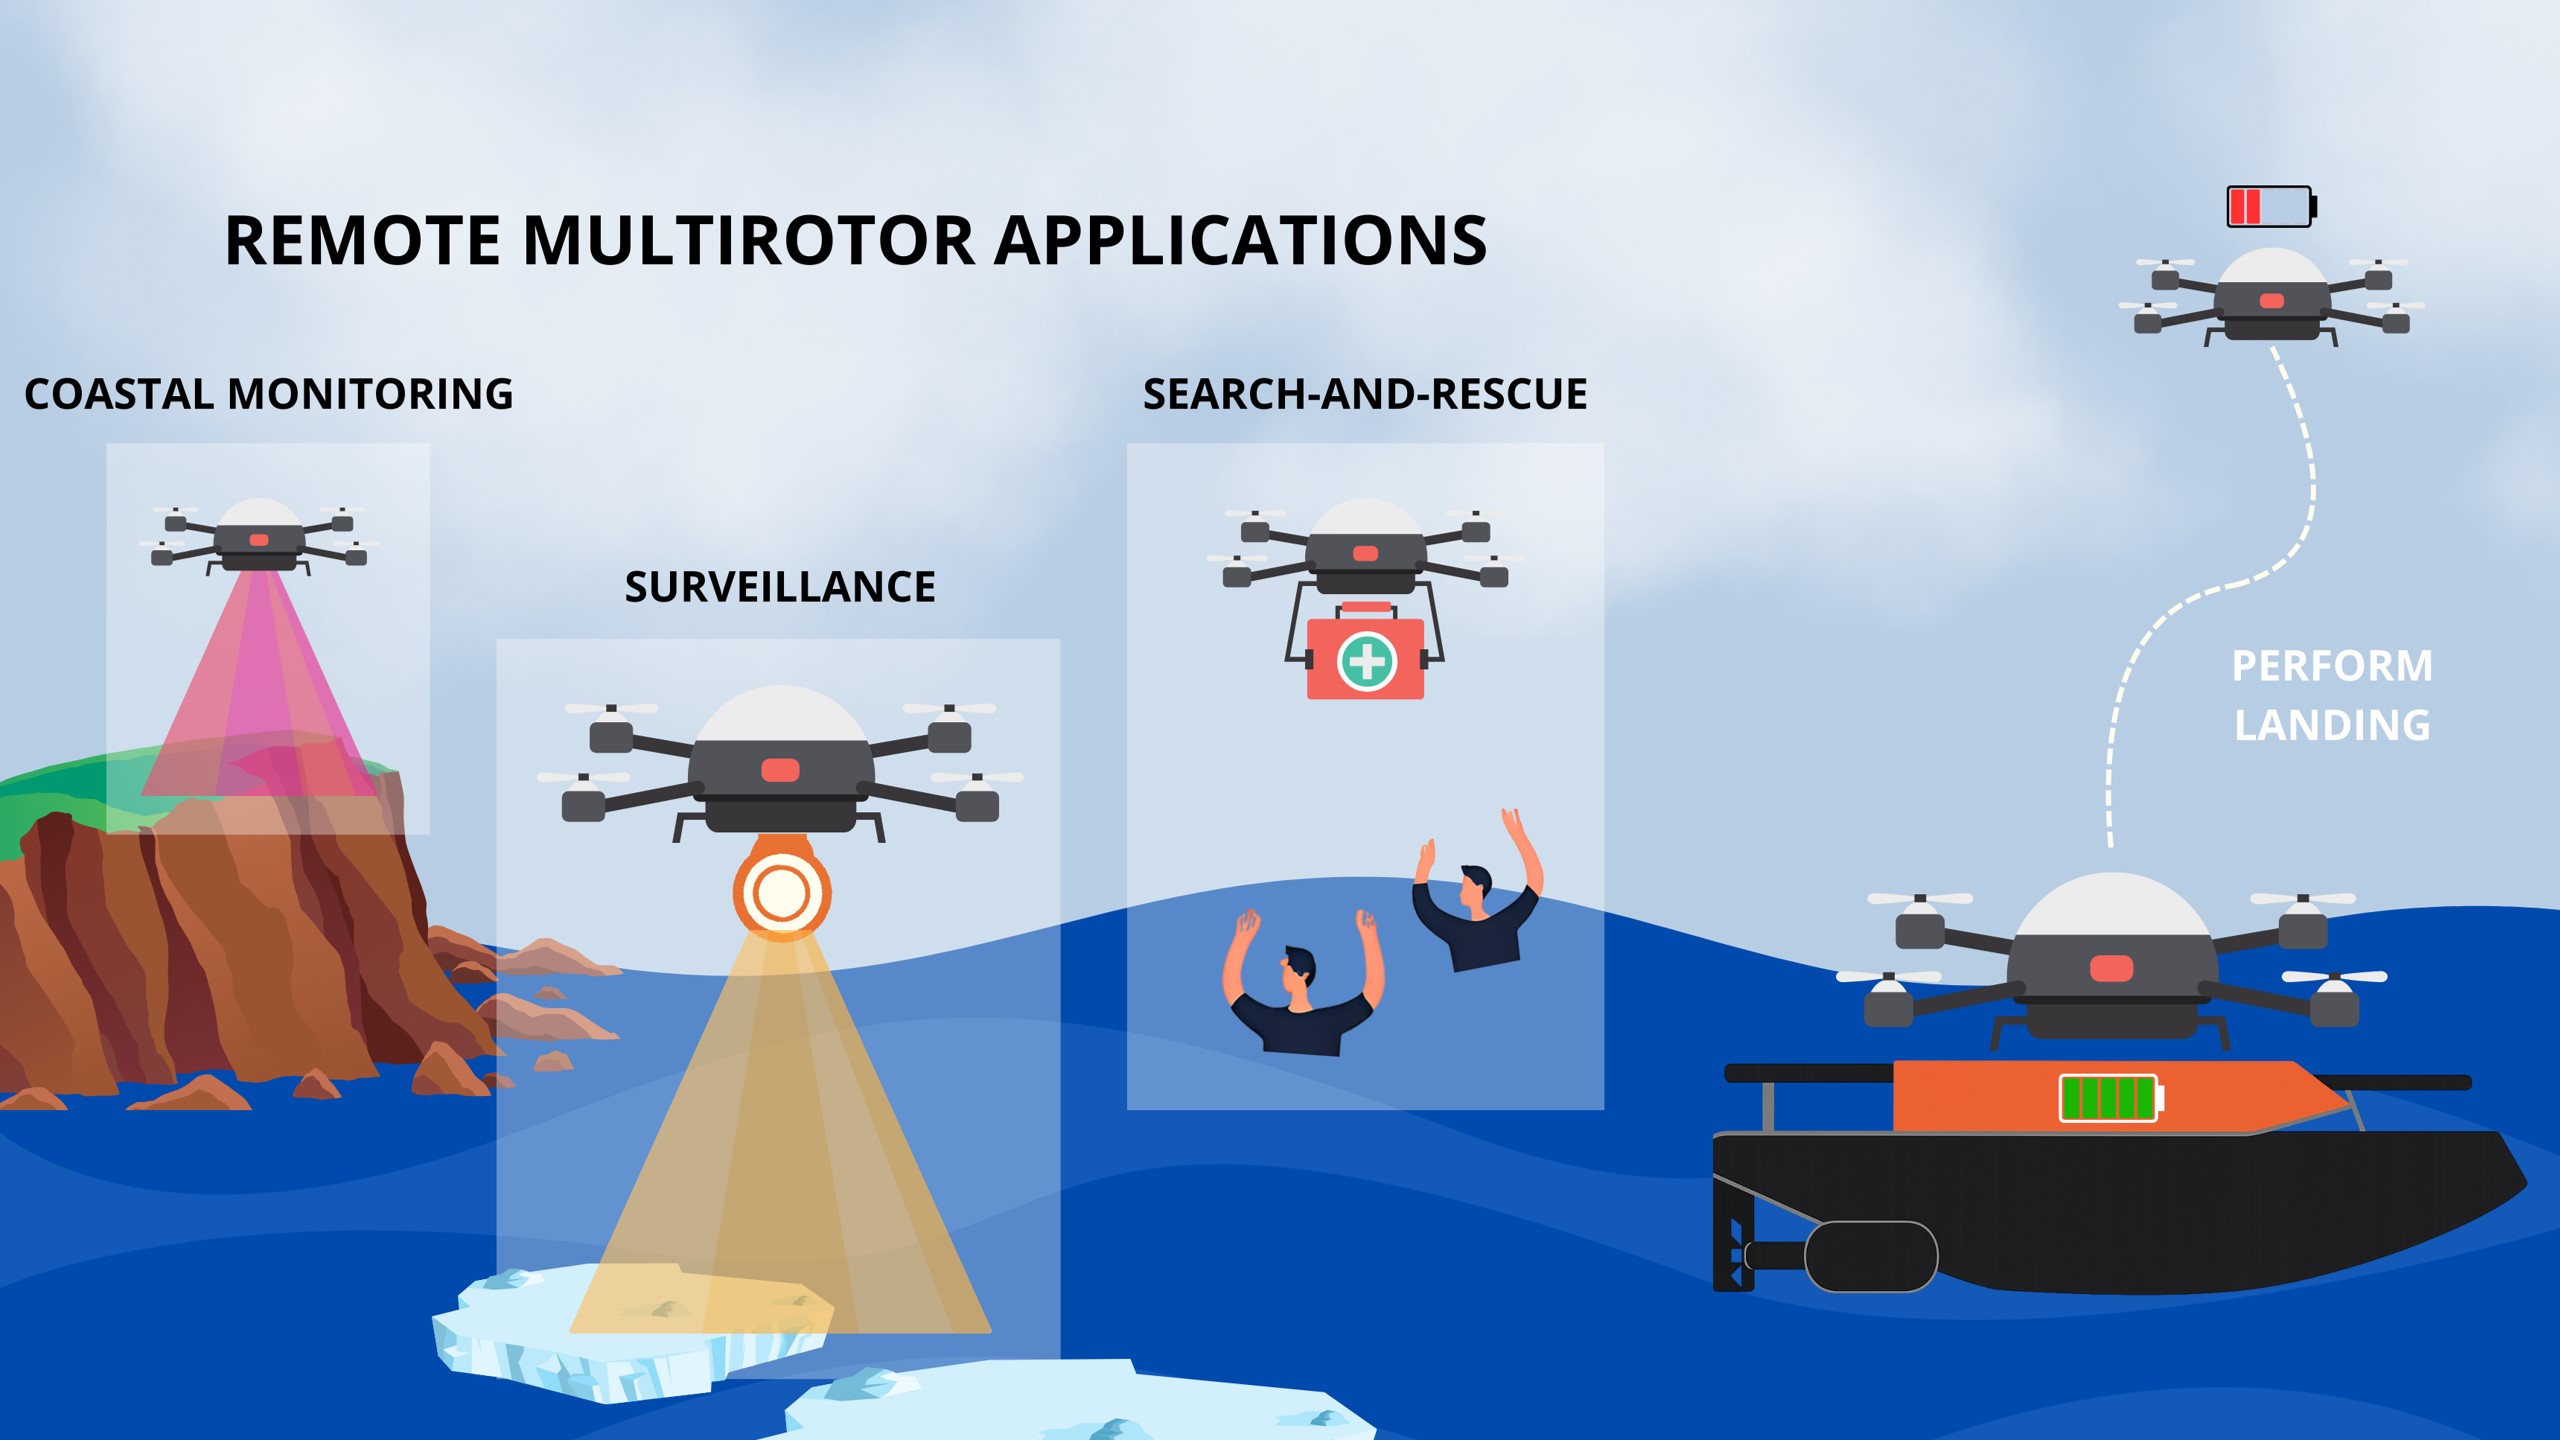
Unmanned aerial vehicles (UAV) are invaluable to challenging remote applications, including coastal monitoring, surveillance for safe passage in icy waterways, and search-and-rescue missions. However, after deployment in a remote setting, the functional life of the multirotor is ultimately limited by its battery life. The research we continue to investigate is the ability to cooperatively and autonomously land a multirotor on an uncrewed surface vessel (USV) for recharging. We address this problem in real time with safe control algorithms that we apply on a Crazyflie.

Approach

Our approach enables the Crazyflie to cooperatively coordinate, with a simulated USV, a safe landing in severe wave conditions. It is critical to the autonomy of the system that the agents do not know when or where they’re going to land at the outset, they are cooperating in real time to make these determinations. The novelty of this work is three primary contributions:

Learning a Spatial-Temporal Wave Model as a Gaussian Process

We first learn the local tilt model, representative of the spatial and temporal impact of waves on the tilt angle of a USV, using Gaussian Process (GP) regression. Prior to the execution of the landing, the USV collects Nd noisy observations D = {q, t, φ²}, where q is the position of the USV, t is time, and φ is the tilt angle of the USV. We use GP regression to learn the spatial-temporal tilt model: fw(q, t) = (φ(q, t))² . The predicted tilt and uncertainty, conditioned on the observed data D, at a query point a = [q, t] can be inferred using the posterior distribution.

Distributed Model Predictive Control

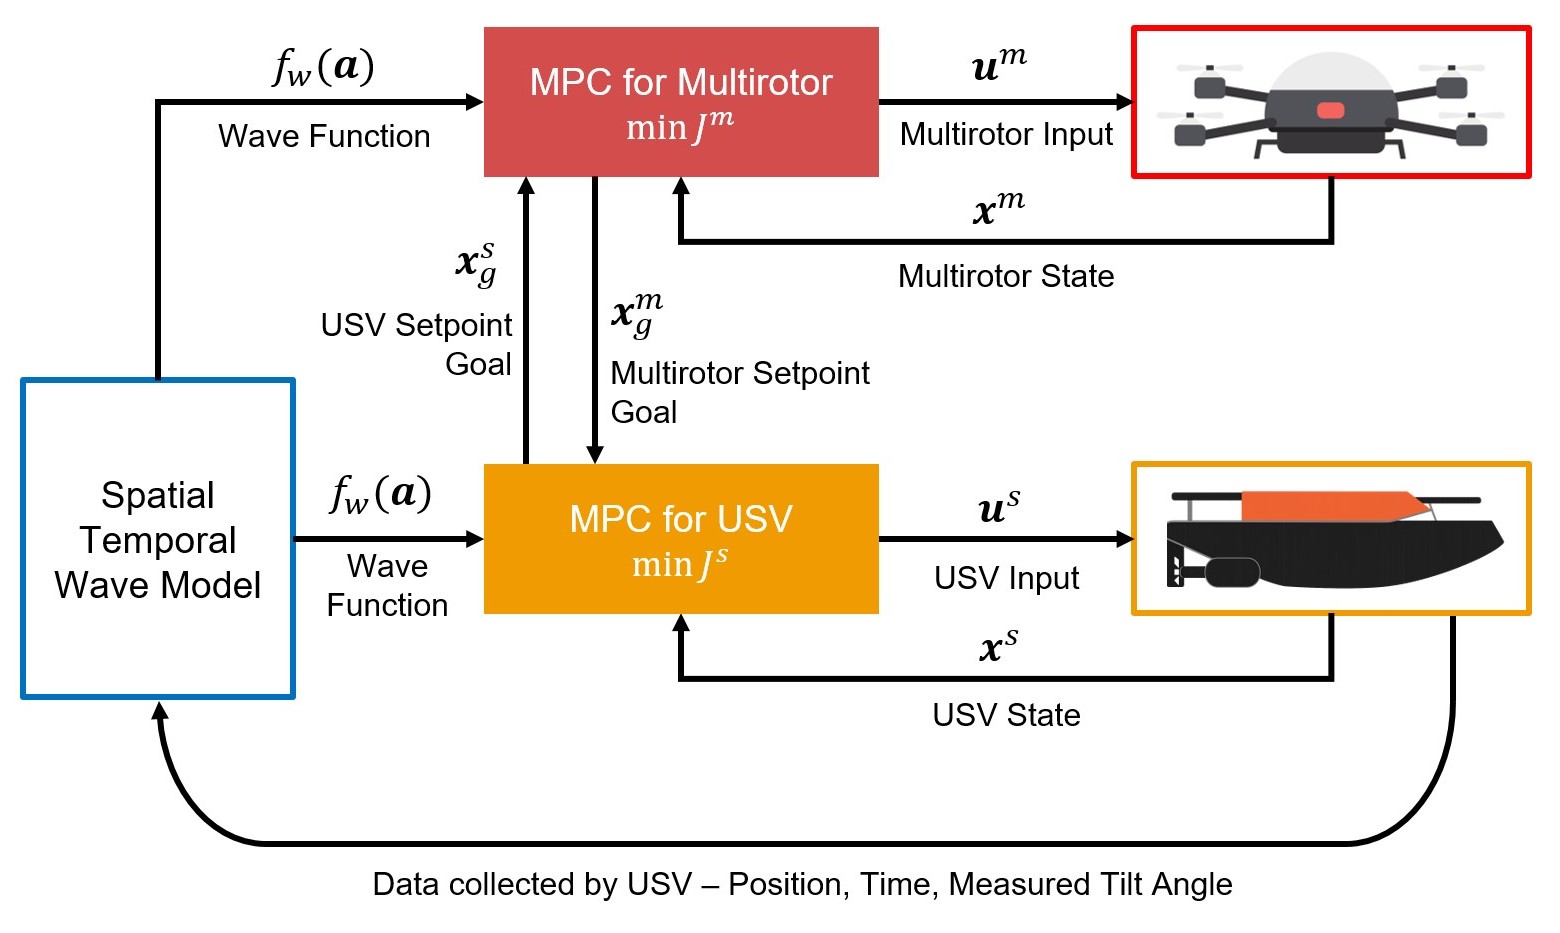
Our proposed model predictive control (MPC) architecture combines standard tracking MPCs for the Crazyflie and USV and augments them with additional artificial goal locations. These artificial goals enable the vehicles to coordinate without prior guidance. Each vehicle solves an individual optimization problem for both the artificial goal and an input that tracks it but only communicates the former to the other vehicle. The MPC integrates, into the cost functions for both vehicles, the learned mean and uncertainty quantification of the spatial-temporal wave model from the GP regression. This encourages the agents to converge to calmer waters enabling safer landings in variable wave conditions.

Low-Cost USV Simulation Testbed Platform

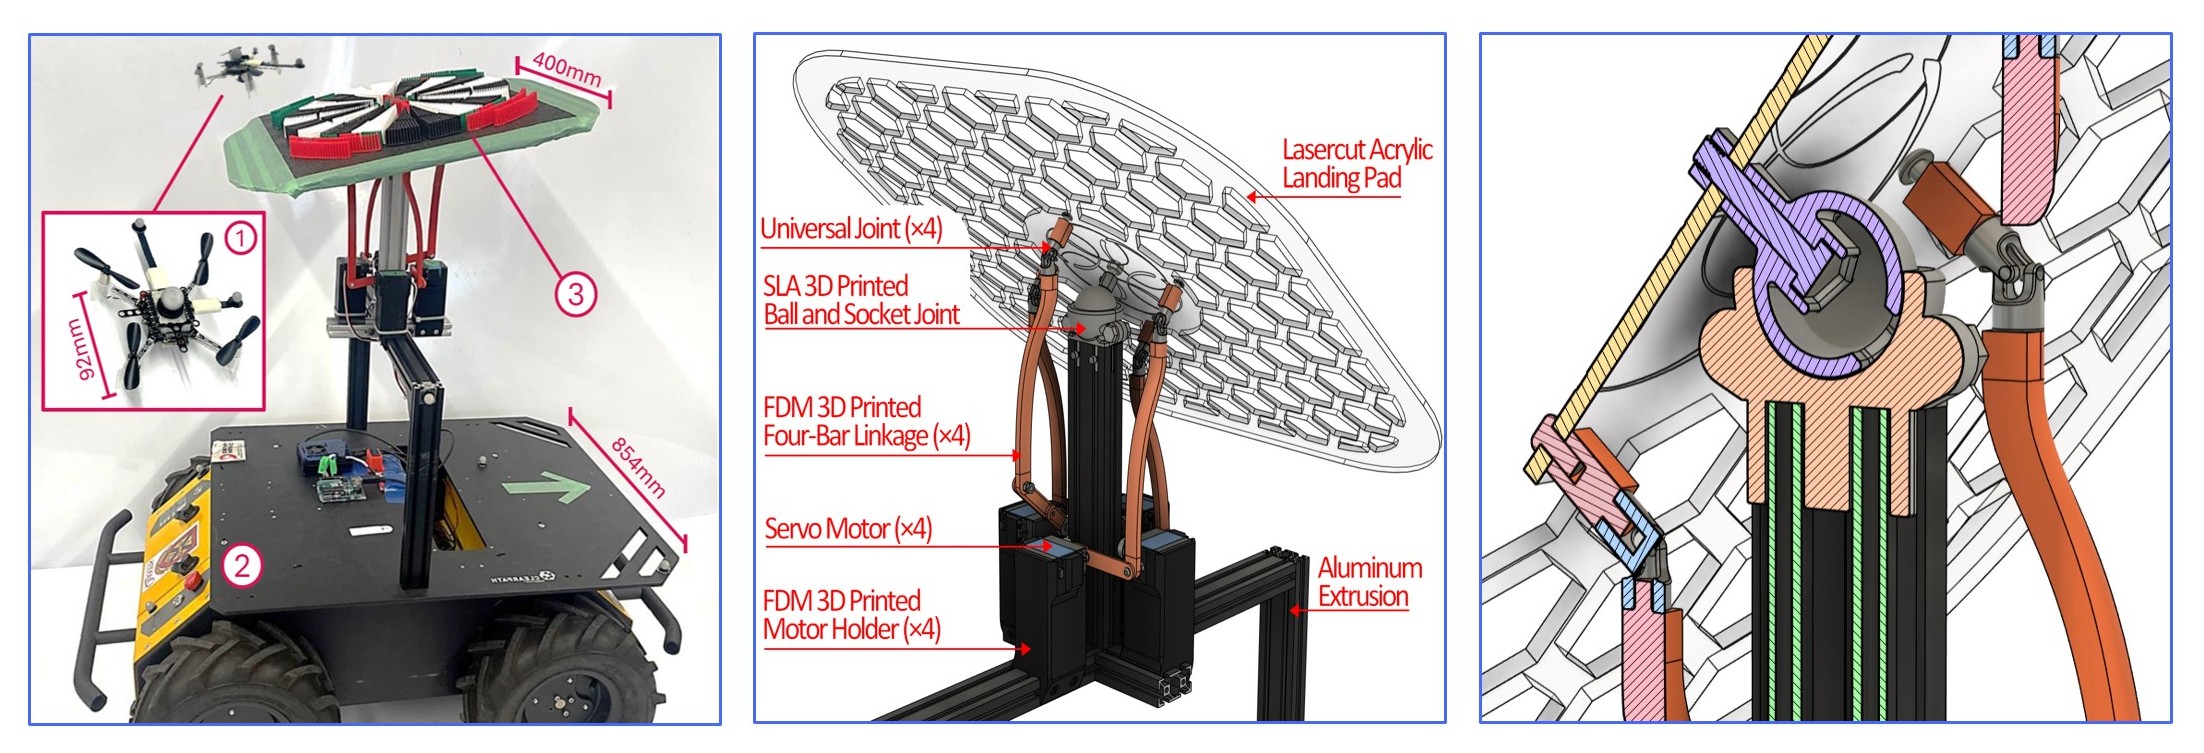
To validate the proposed MPC scheme for landing on a USV, we simulate the spatial-temporal motion of a USV in waves of variable intensity using a custom tilting platform. The custom tilting platform has two degrees of freedom (roll, pitch) and is affixed to the deck of a differential-drive unmanned ground vehicle (UGV), the ClearPath Robotics Husky. We selected a differential-drive UGV to replicate the motion of a broad range of USVs, including those with differential drive and conventional rudder steering. Our platform is low-cost, modular, and open source, enabling rapid testing and benchmarking of UAV-USV landing strategies indoors before going onto the water which is high-risk and expensive. 

Block diagram of our proposed distributed model predictive control scheme.
Overview of the USV simulation testbed tilting platform for ground vehicles. Left: the platform is shown mounted on the deck of the ClearPath Robotics Husky with the Crazyflie 2.1 hovering above. Center: a closer view of the landing pad configuration and platform components. Right: Section view showing the ball-and-socket joint and the linkage mechanism.

Experimental Setup

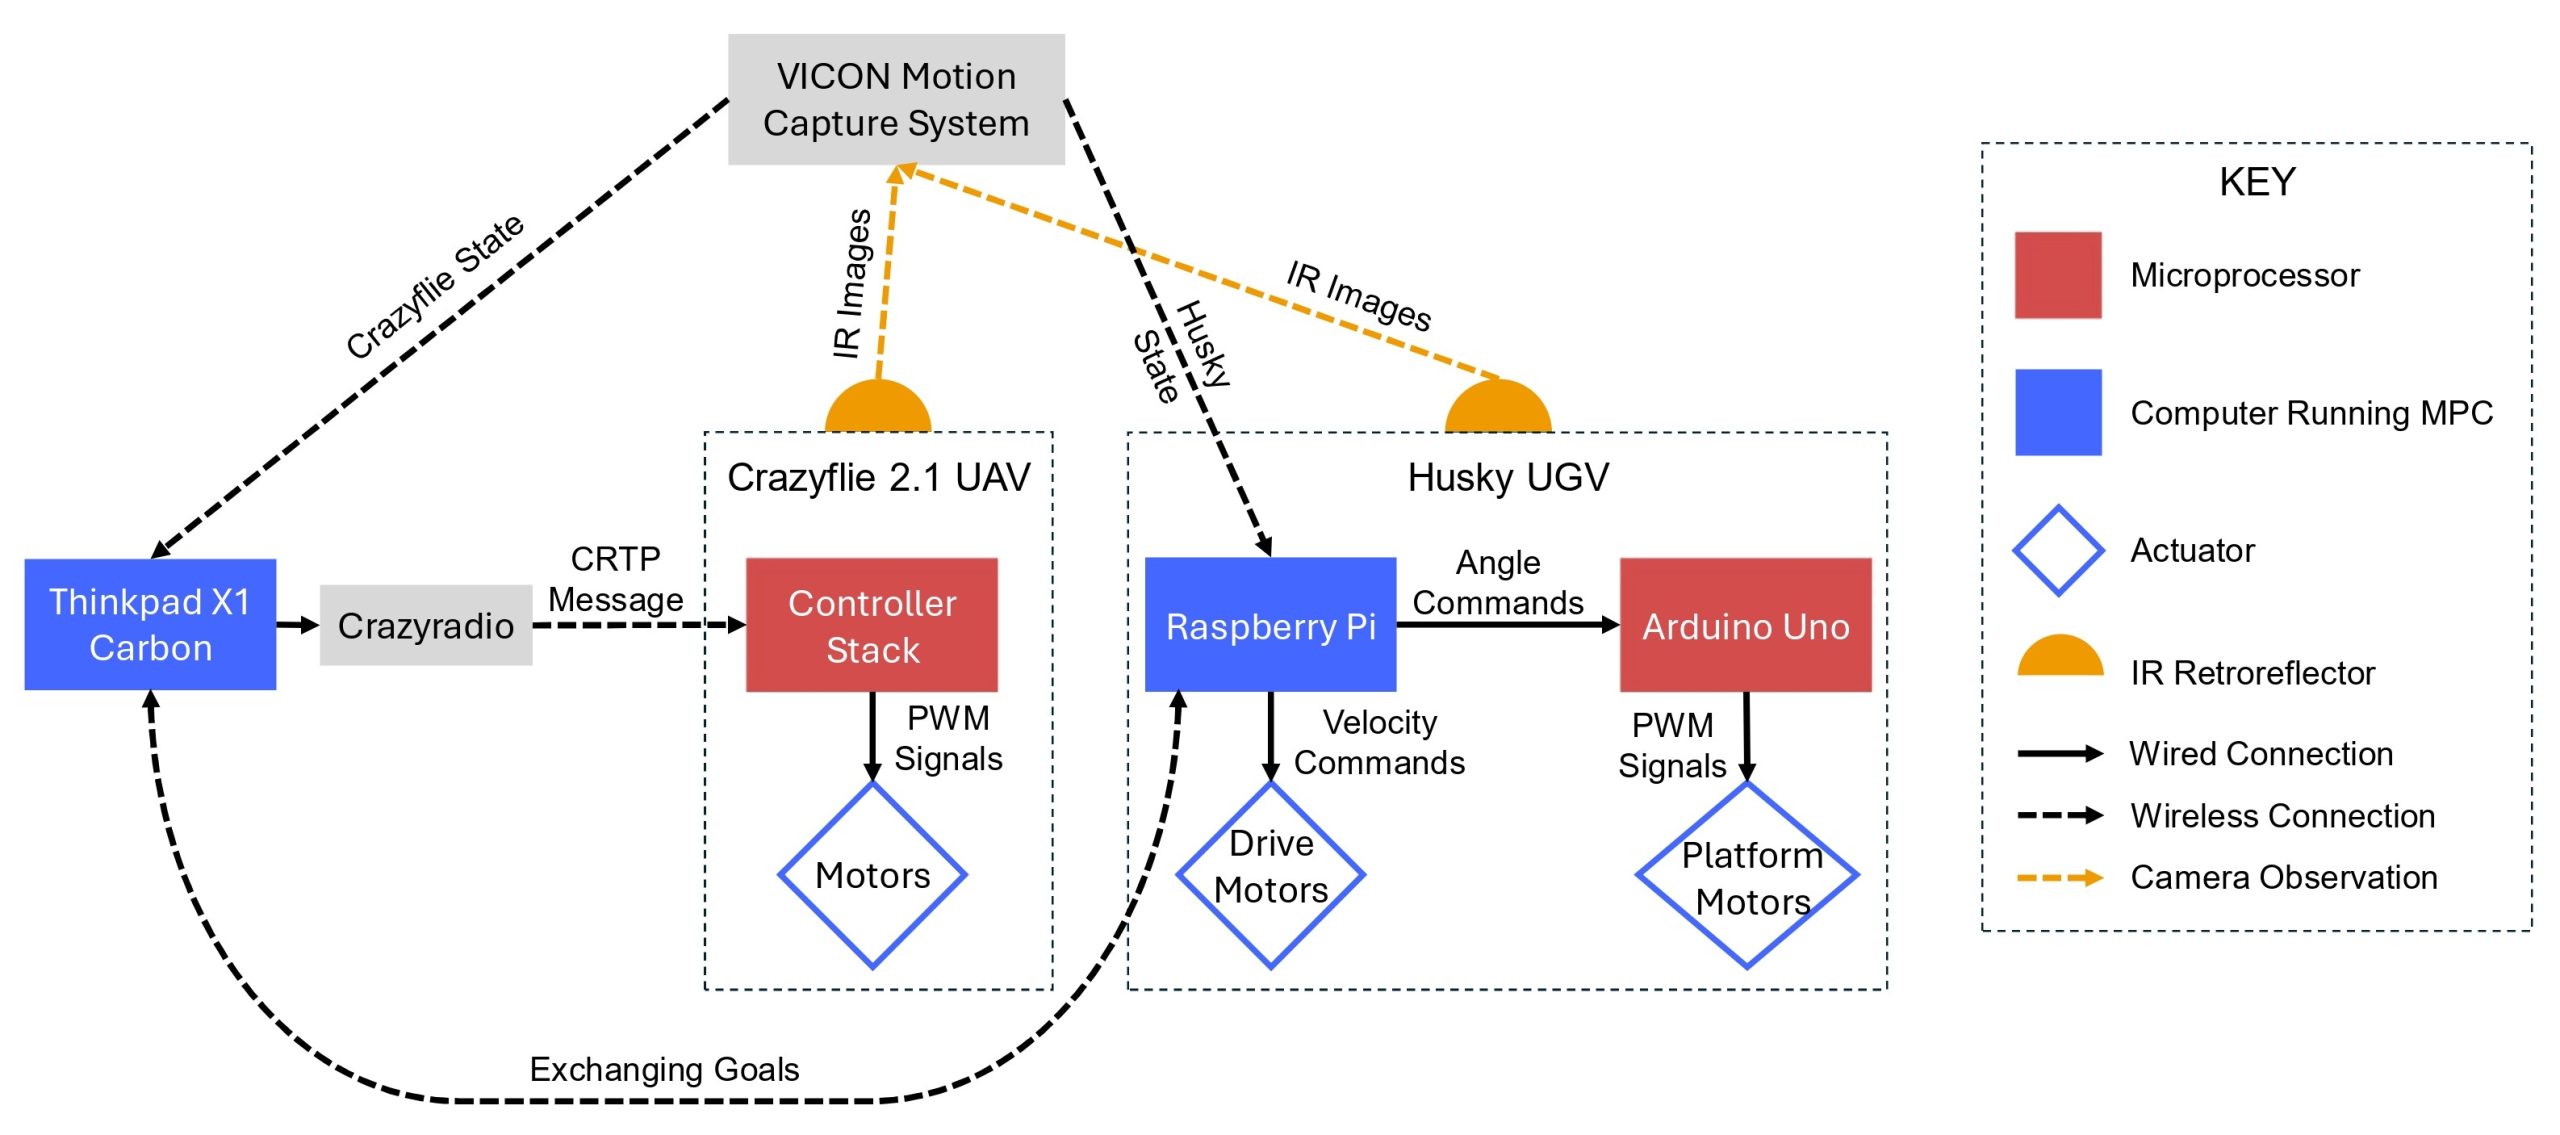
Full system architecture.

We evaluate the proposed MPC scheme for UAV-USV cooperative landing in indoor experiments using the Crazyflie 2.1 and our tilting platform. These experiments represent a scaled-down version of real-world harsh wave conditions. Amplitude and frequency are informed by a survey of waves along the coastlines of the Great Lakes of North America. We select a spatially decaying sine wave whose amplitude decreases gradually with increasing x-position. We expect the Crazyflie and the simulated USV to cooperatively select the safest landing spatially and temporally by learning the GP and incorporating it the MPC scheme.

The UAV MPC is run off-board on a Thinkpad X1 Carbon with Intel Core i7-1270P Processor. The MPC runs at a frequency of 50Hz and transmits control inputs to the Crazyflie via long range Crazyradio USB. The Raspberry Pi onboard the Husky runs its MPC at 10Hz. The two vehicles communicate their goals using ROS topics on a local WiFi network and receive their own pose feedback at 240 Hz from a VICON motion capture system.

Experimental Results

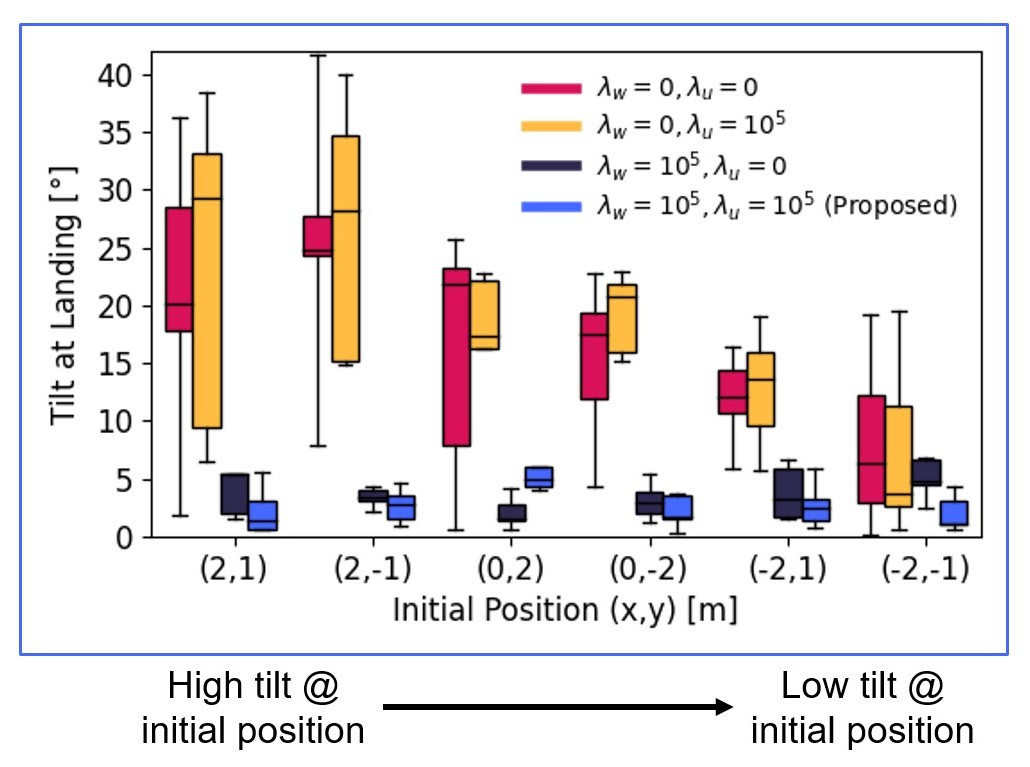
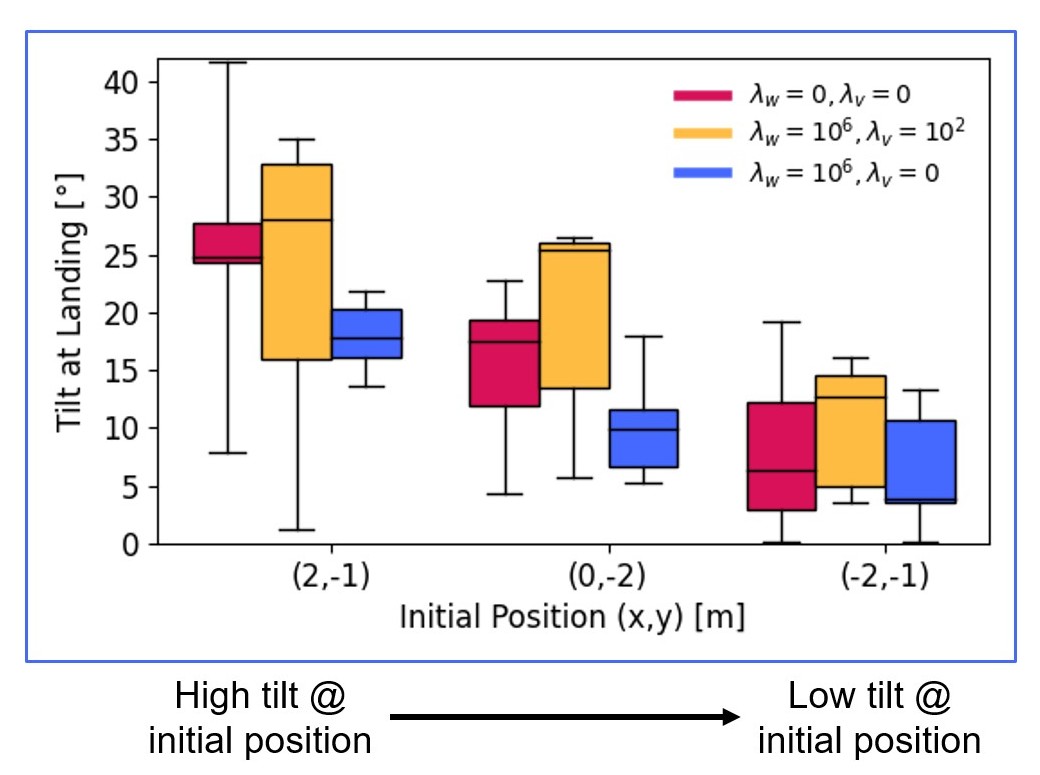
Experiment 1. We define the tilt model. Our proposed distributed MPC scheme can locate a low-tilt landing location from all six initial platform positions.
Experiment 2. We learn the wave model using a GP. The MPC scheme can locate a low-tilt landing location from all three initial platform positions.

In the first set of experiments, we assume no uncertainty in the tilt model. We compare four MPC weighting strategies ranging from a purely cooperative strategy in red (where neither vehicle weights wave tilt in the MPC, neglecting spatial-temporal tilt motion), to our proposed strategy in blue (where both vehicles weight wave tilt highly in the MPC). In this set of experiments, our proposed approach (blue) reduces the tilt angle of the platform at landing by between 68-89% and results in a 53% increase in landing success rate over the purely cooperative strategy (red).

In the second set of experiments, we learn the wave tilt model as a GP. We compare the purely cooperative strategy in red from before to our proposed strategy in blue where we weight the posterior mean cost from the GP regression. In this set of experiments, our proposed approach (blue) reduces tilt angle of the platform at landing by 23-32% and results in a 47% increase in the landing success rate over pure cooperation (red).

Future Work

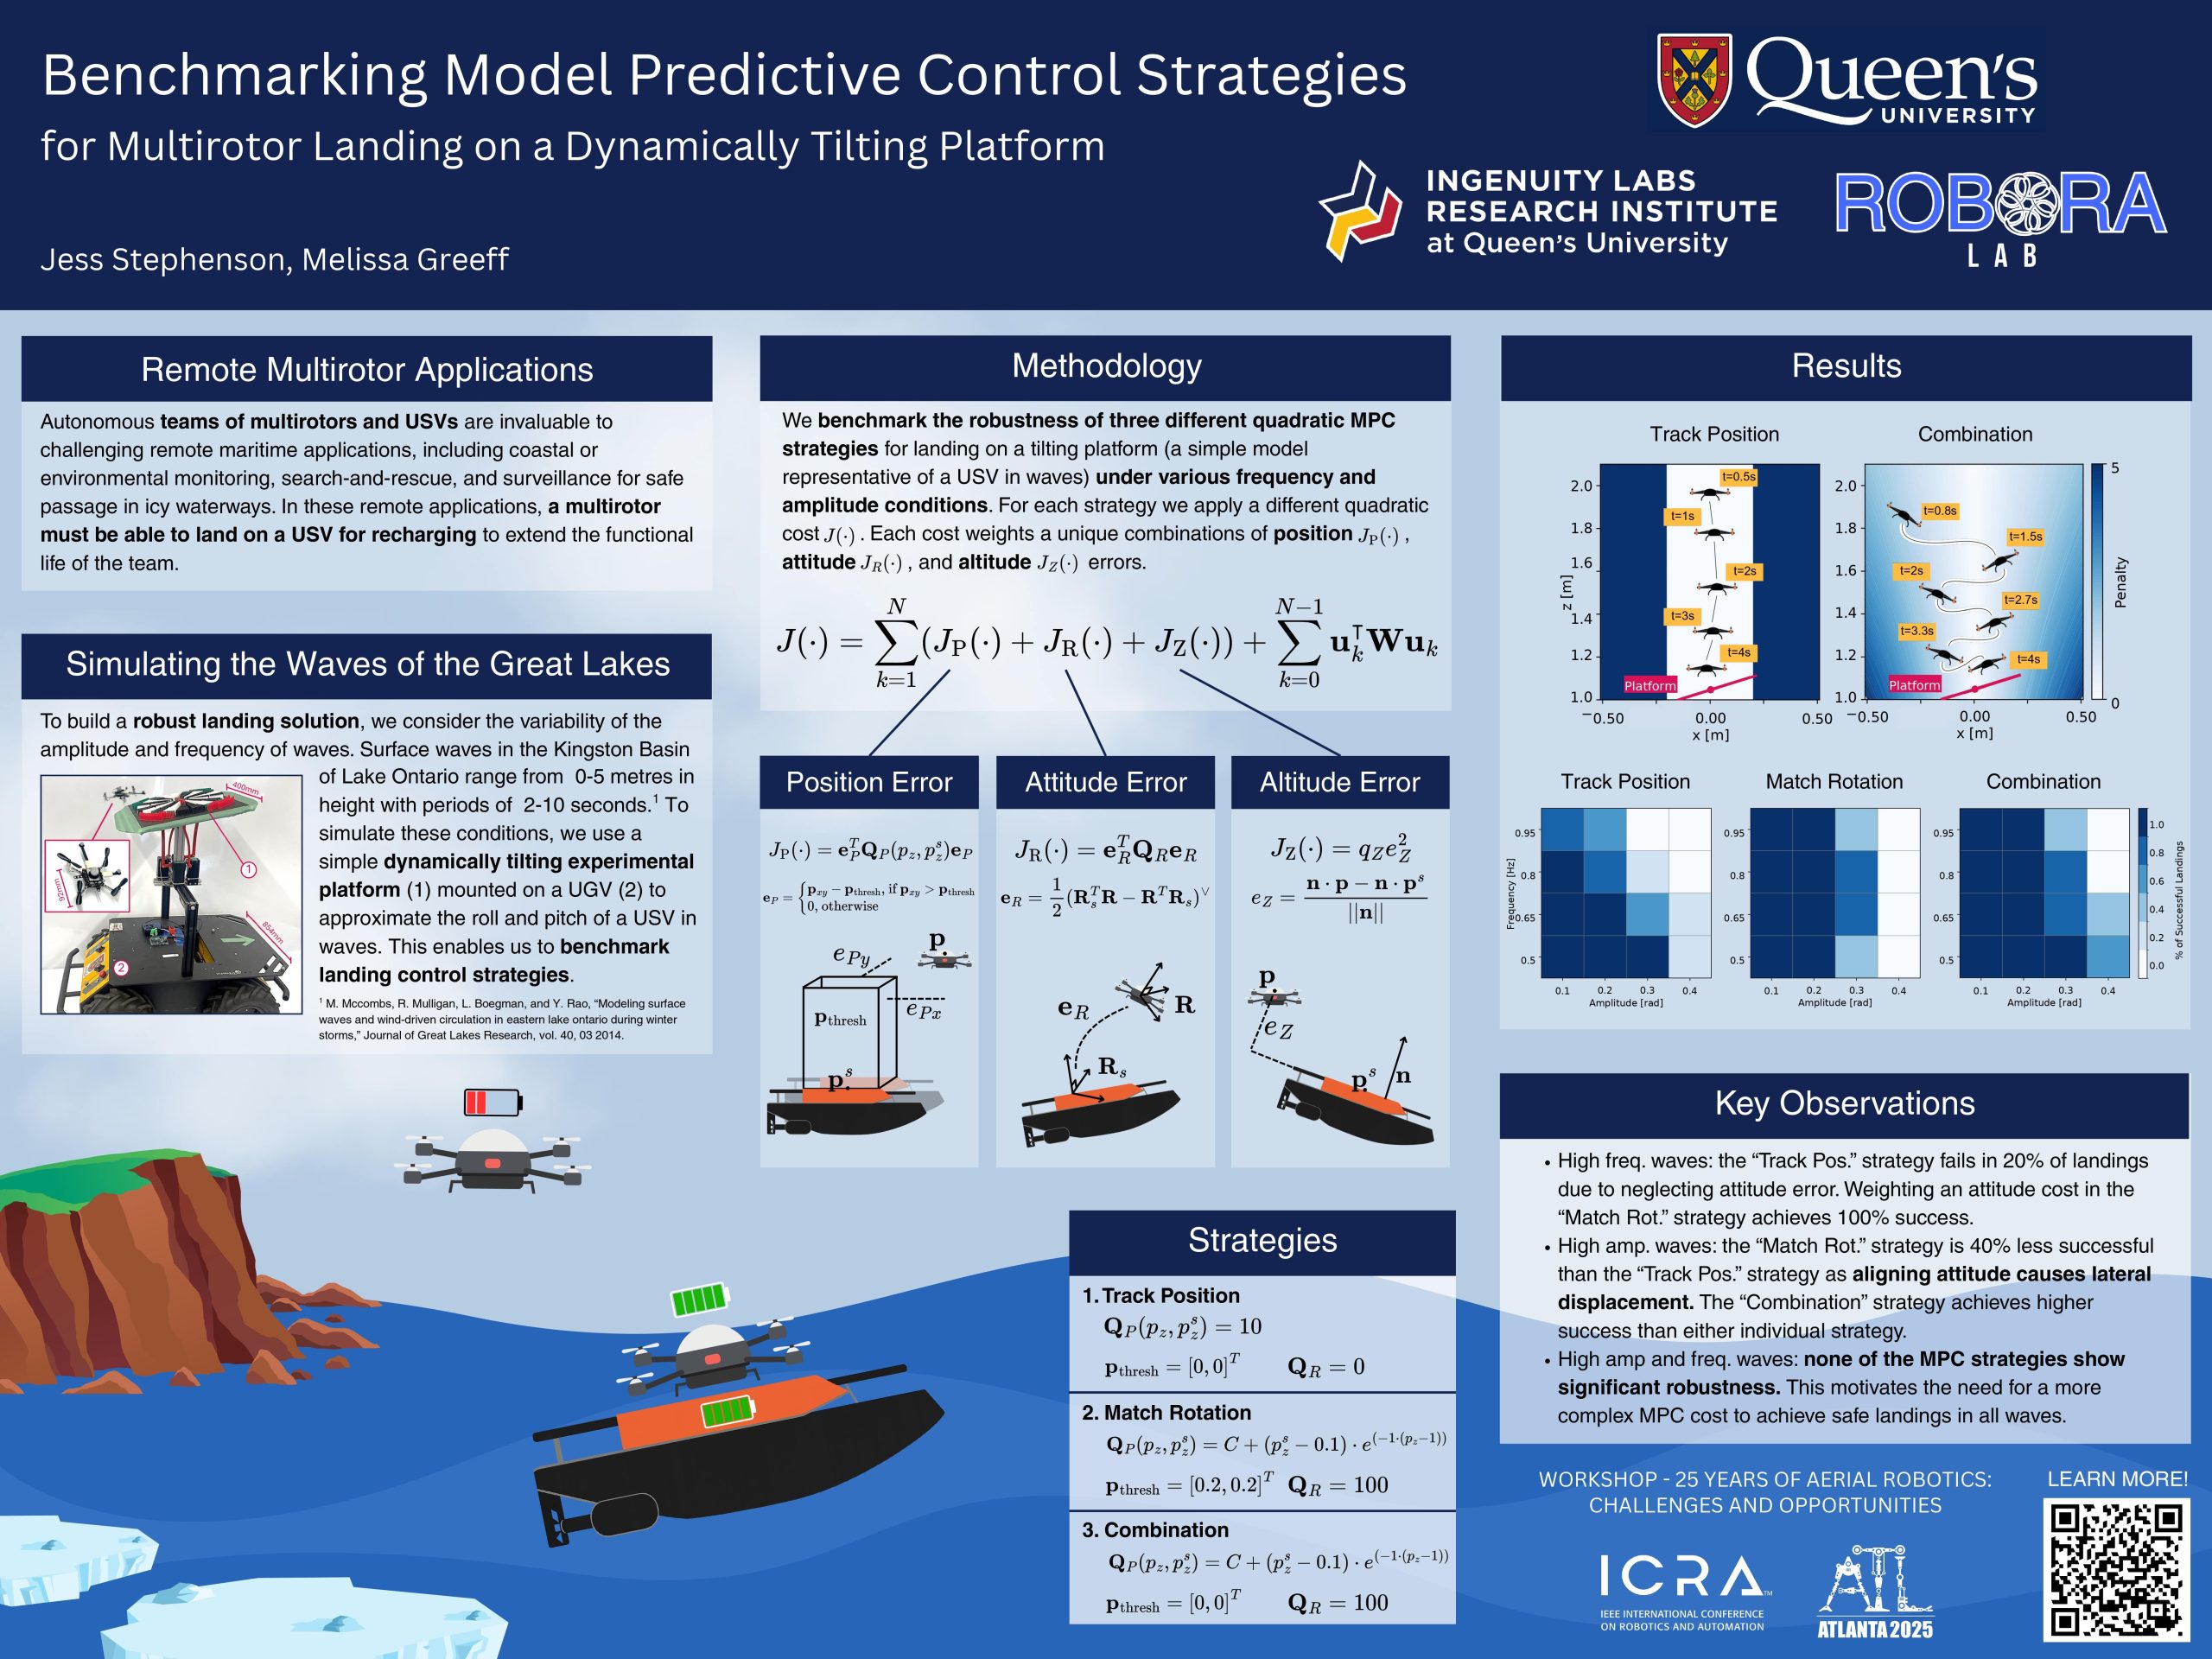
In the work presented above we assume that there is a local region with calm waves that can be reached by both vehicles to then perform a safe landing. However, in practical scenarios, spatial-temporal assumptions are not realistic if an emergency landing is necessary or if time and resources are constrained. Recently, we explored quadratic MPC strategies for landing a Crazyflie on the tilting platform in high frequency high amplitude conditions. In these strategies we include optimization costs that weigh position, attitude, and altitude errors between the multirotor and the platform.

Though all strategies successfully land in low-frequency, low-amplitude conditions, they have low success in the higher-amplitude conditions. Therefore, designing a safe controller that is robust to a wide range of wave amplitudes and frequencies is an ongoing research area.

Poster presented at the workshop ’25 Years of Aerial Robotics: Challenges and Opportunities’ at ICRA 2025.

Links

A couple of weeks ago, we were at ICRA 2025 in Atlanta. This year’s ICRA drew over 7,000 attendees, making it the biggest edition yet. We had a booth at the exhibition where we showed our decentralized swarm demo. The setup included a mix of Crazyflie 2.1+ units with Qi charging decks and Crazyflie 2.1 Brushless platforms with our new charging dock. The entire swarm operated onboard, with two Lighthouse base stations for positioning. More details about the setup can be found in the recent swarm demo blog post.

8 Crazyflies flying simultaneously in our decentralized swarm at ICRA 2025

Some of the brushless drones carried our high-powered LED deck prototype to make the swarm more visible and engaging. One of the drones also had a prototype camera streaming deck, which held up well despite the busy wireless environment.

A Different Perspective

This year we were also invited to participate in a workshop: 25 Years of Aerial Robotics: Challenges and Opportunities, where I (Rik) gave a short presentation about the evolution of positioning in the Crazyflie, from webcam-based AruCo marker tracking to the systems we use today.

Usually, we spend most of our time on the exhibition floor, so being part of a workshop like this was a different experience. It was interesting to hear researchers mention the Crazyflie in their work without needing to explain what it is. That kind of familiarity isn’t something we take for granted, and it was nice to see.

The workshop also gave us a chance to talk with both established researchers and newer faces in the field. What stood out most was hearing how people are using the Crazyflie in their work today. It’s very rewarding to see how what we do at the office connects with and supports real research.

Catching Up and Looking Around

One of the most rewarding parts of the conference was the chance to connect directly with people using the platform. We talked to many users, both current and past, and saw new research based on the platform. It was also great to reconnect with Flapper Drones, who build flapping-wing vehicles powered by the Crazyflie Bolt. And it was nice to see HopTo on the exhibition floor for the first time. The company is a spin-off from the Robotics and Intelligent Systems Lab at CityU Hong Kong, which published a Science Robotics paper on the hopcopter concept that used a Crazyflie. We also had the chance to catch up with a maintainer of CrazySim, an open-source simulator in the Crazyflie ecosystem. It’s always valuable to connect with people building on top of the platform, whether through research, hardware, or open-source tools.

Wrapping Up

ICRA 2025 was packed with activity. From demoing the swarm, to the workshop, to hallway conversations, it gave us a lot of valuable feedback and insight. Thanks to everyone who stopped by, joined a talk, or came to say hello.

This week in Germany

This week, some of us are on an adventure!
Marcus and Tobias will be exploring both the RIG and Embedded World fairs.

RIG showcases the latest innovations in robotics and intelligent systems, while Embedded World is the place to be for cutting-edge embedded technologies. Both events promise amazing demos, insightful talks, and a chance to catch up with some of our collaborators.

Planning to attend either fair? Let’s meet up! We’d love to explore the exhibitions together, chat about cool technologies, or just geek out about the innovations on display. We’ll be wandering through Embedded World on Thursday and hitting RIG on Friday. Send us an email if you’d like to connect – we’re always up for grabbing coffee!

Next May in Atlanta

After our adventures as visitors, we’re thrilled to announce that we’ll be exhibiting at the International Conference on Robotics and Automation (ICRA) 2025! Stop by our booth where we’ll be showcasing our latest demo. We’ll be, as always, available to discuss our newest products, answer your technical questions, and provide insights into how our solutions can transform your robotics applications. We’re also eager to hear your thoughts on what you’d like to see in our upcoming products. Mark your calendars and make sure to find us at Booth #131 – we may even have some presentations in the work, but nothing confirmed yet.

Today in the shop

And, last but not least, the Brushless is now available in a Swarm configuration! Both the Lighthouse Swarm bundle and Loco Swarm bundle have been added to our shop. These new bundles feature all the same components as our standard Swarm packages, but come equipped with the Crazyflie 2.1 Brushless instead of the Crazyflie 2.1+ model.